KevsRobots Learning Platform
Overview
Setting up the Raspberry Pi 4 environment
Setting Docker for ROS
Build the ROS2 Container
Setting up VSCode
First ROS2 Program
ROS2 Python Packages
Docker and X11
RViz2
Laserscan data
Let's Visualise our Laser scan data
By , Minute
Visualise Laserscan
It’s finally time to visualise the laser scan data.
-
Add Laser_scan topic display - In rviz2, click the
addbutton -
Select Laser_scan - Scroll down the list of displays types and select the
laser scanand clickok
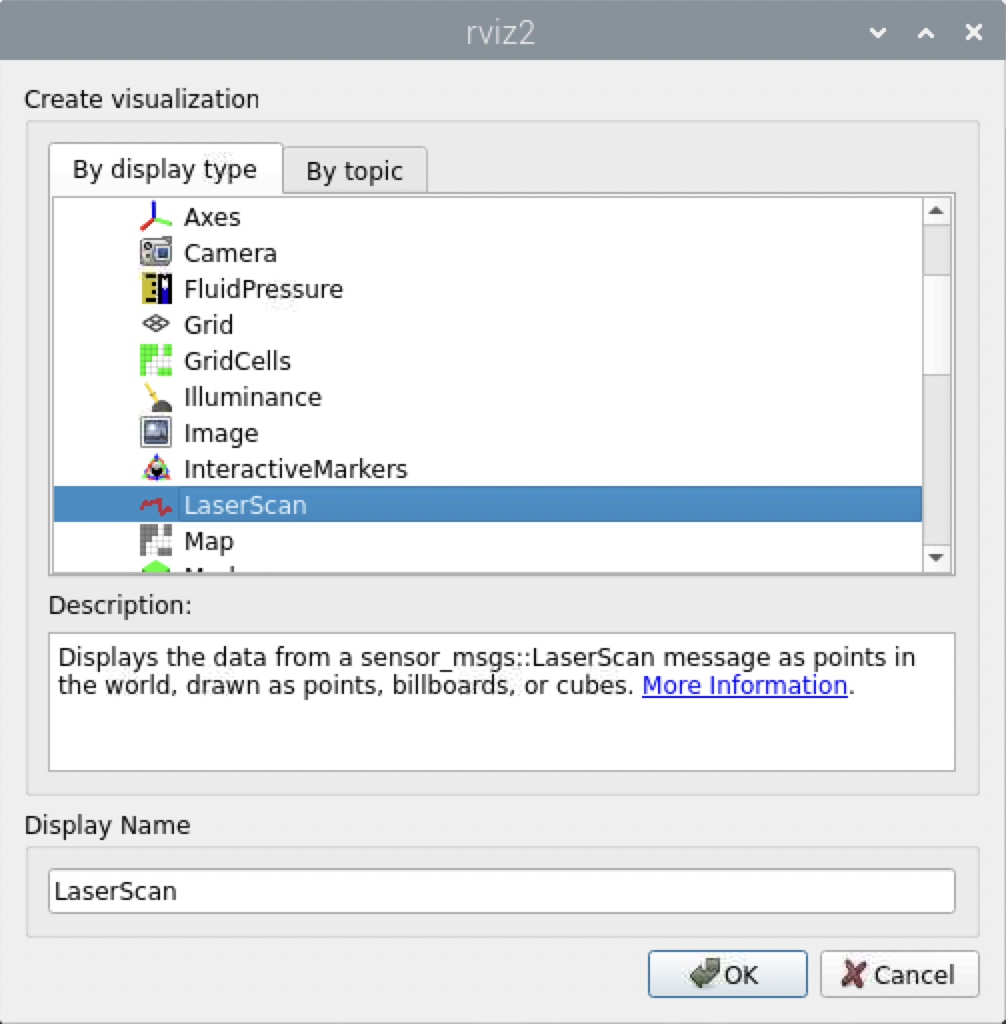
- Set the settings - Click the disclosure triangle next to
LaserScanto open it up
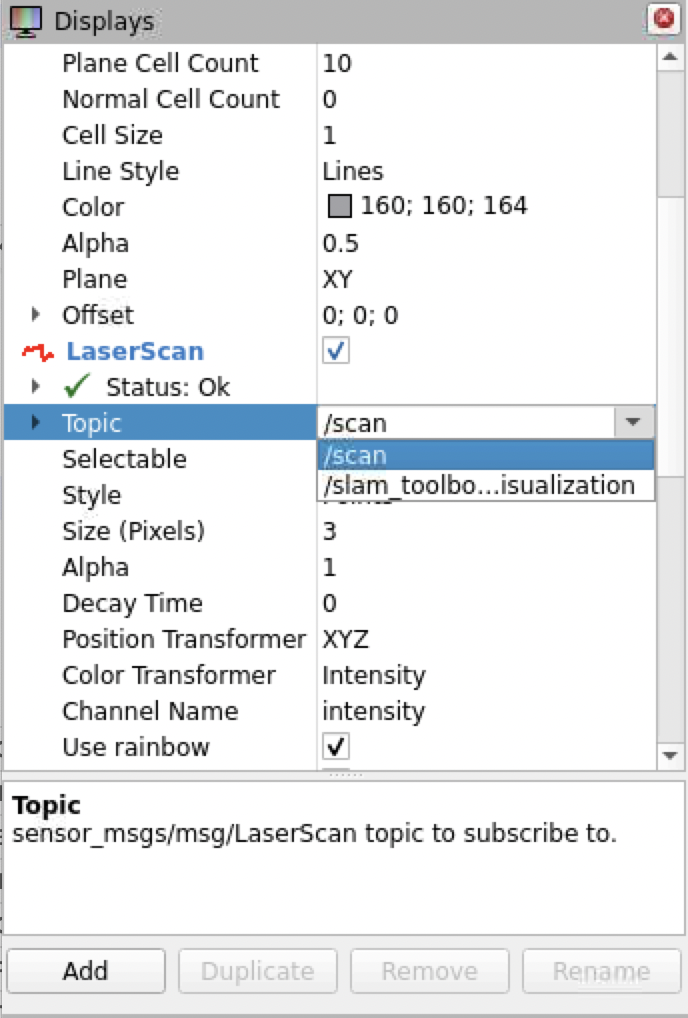
- Change topic to scan - Change the topic to
/scan
- Change the Fixed Frame to world - Under
Global Options, change theFixed Frametoworld
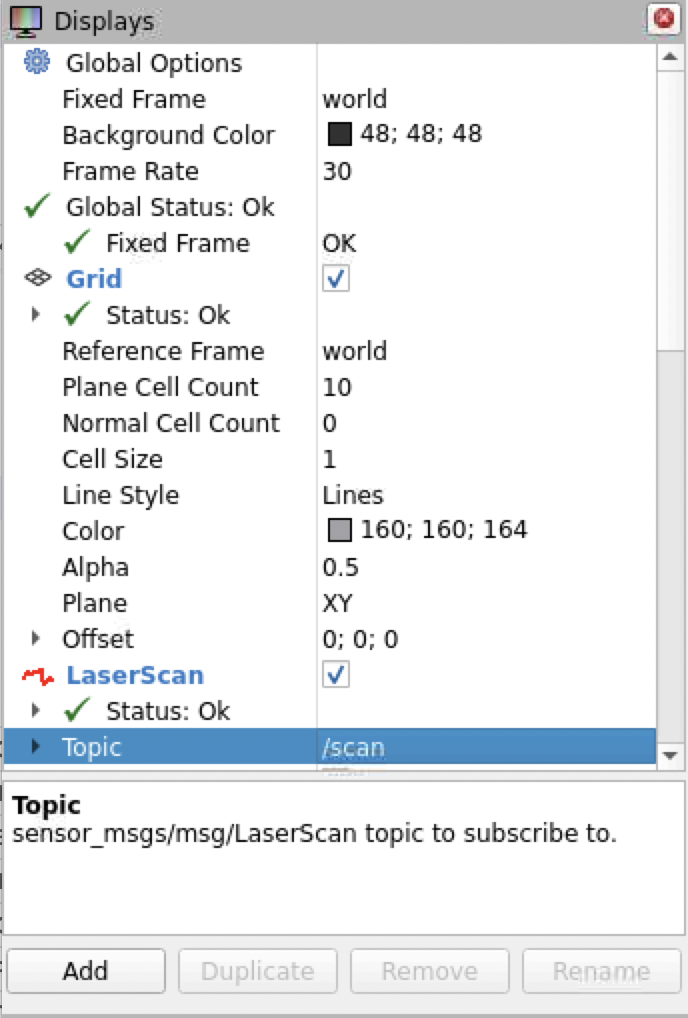
🥳 you should now be able to see the Lidar Data in the middle panel
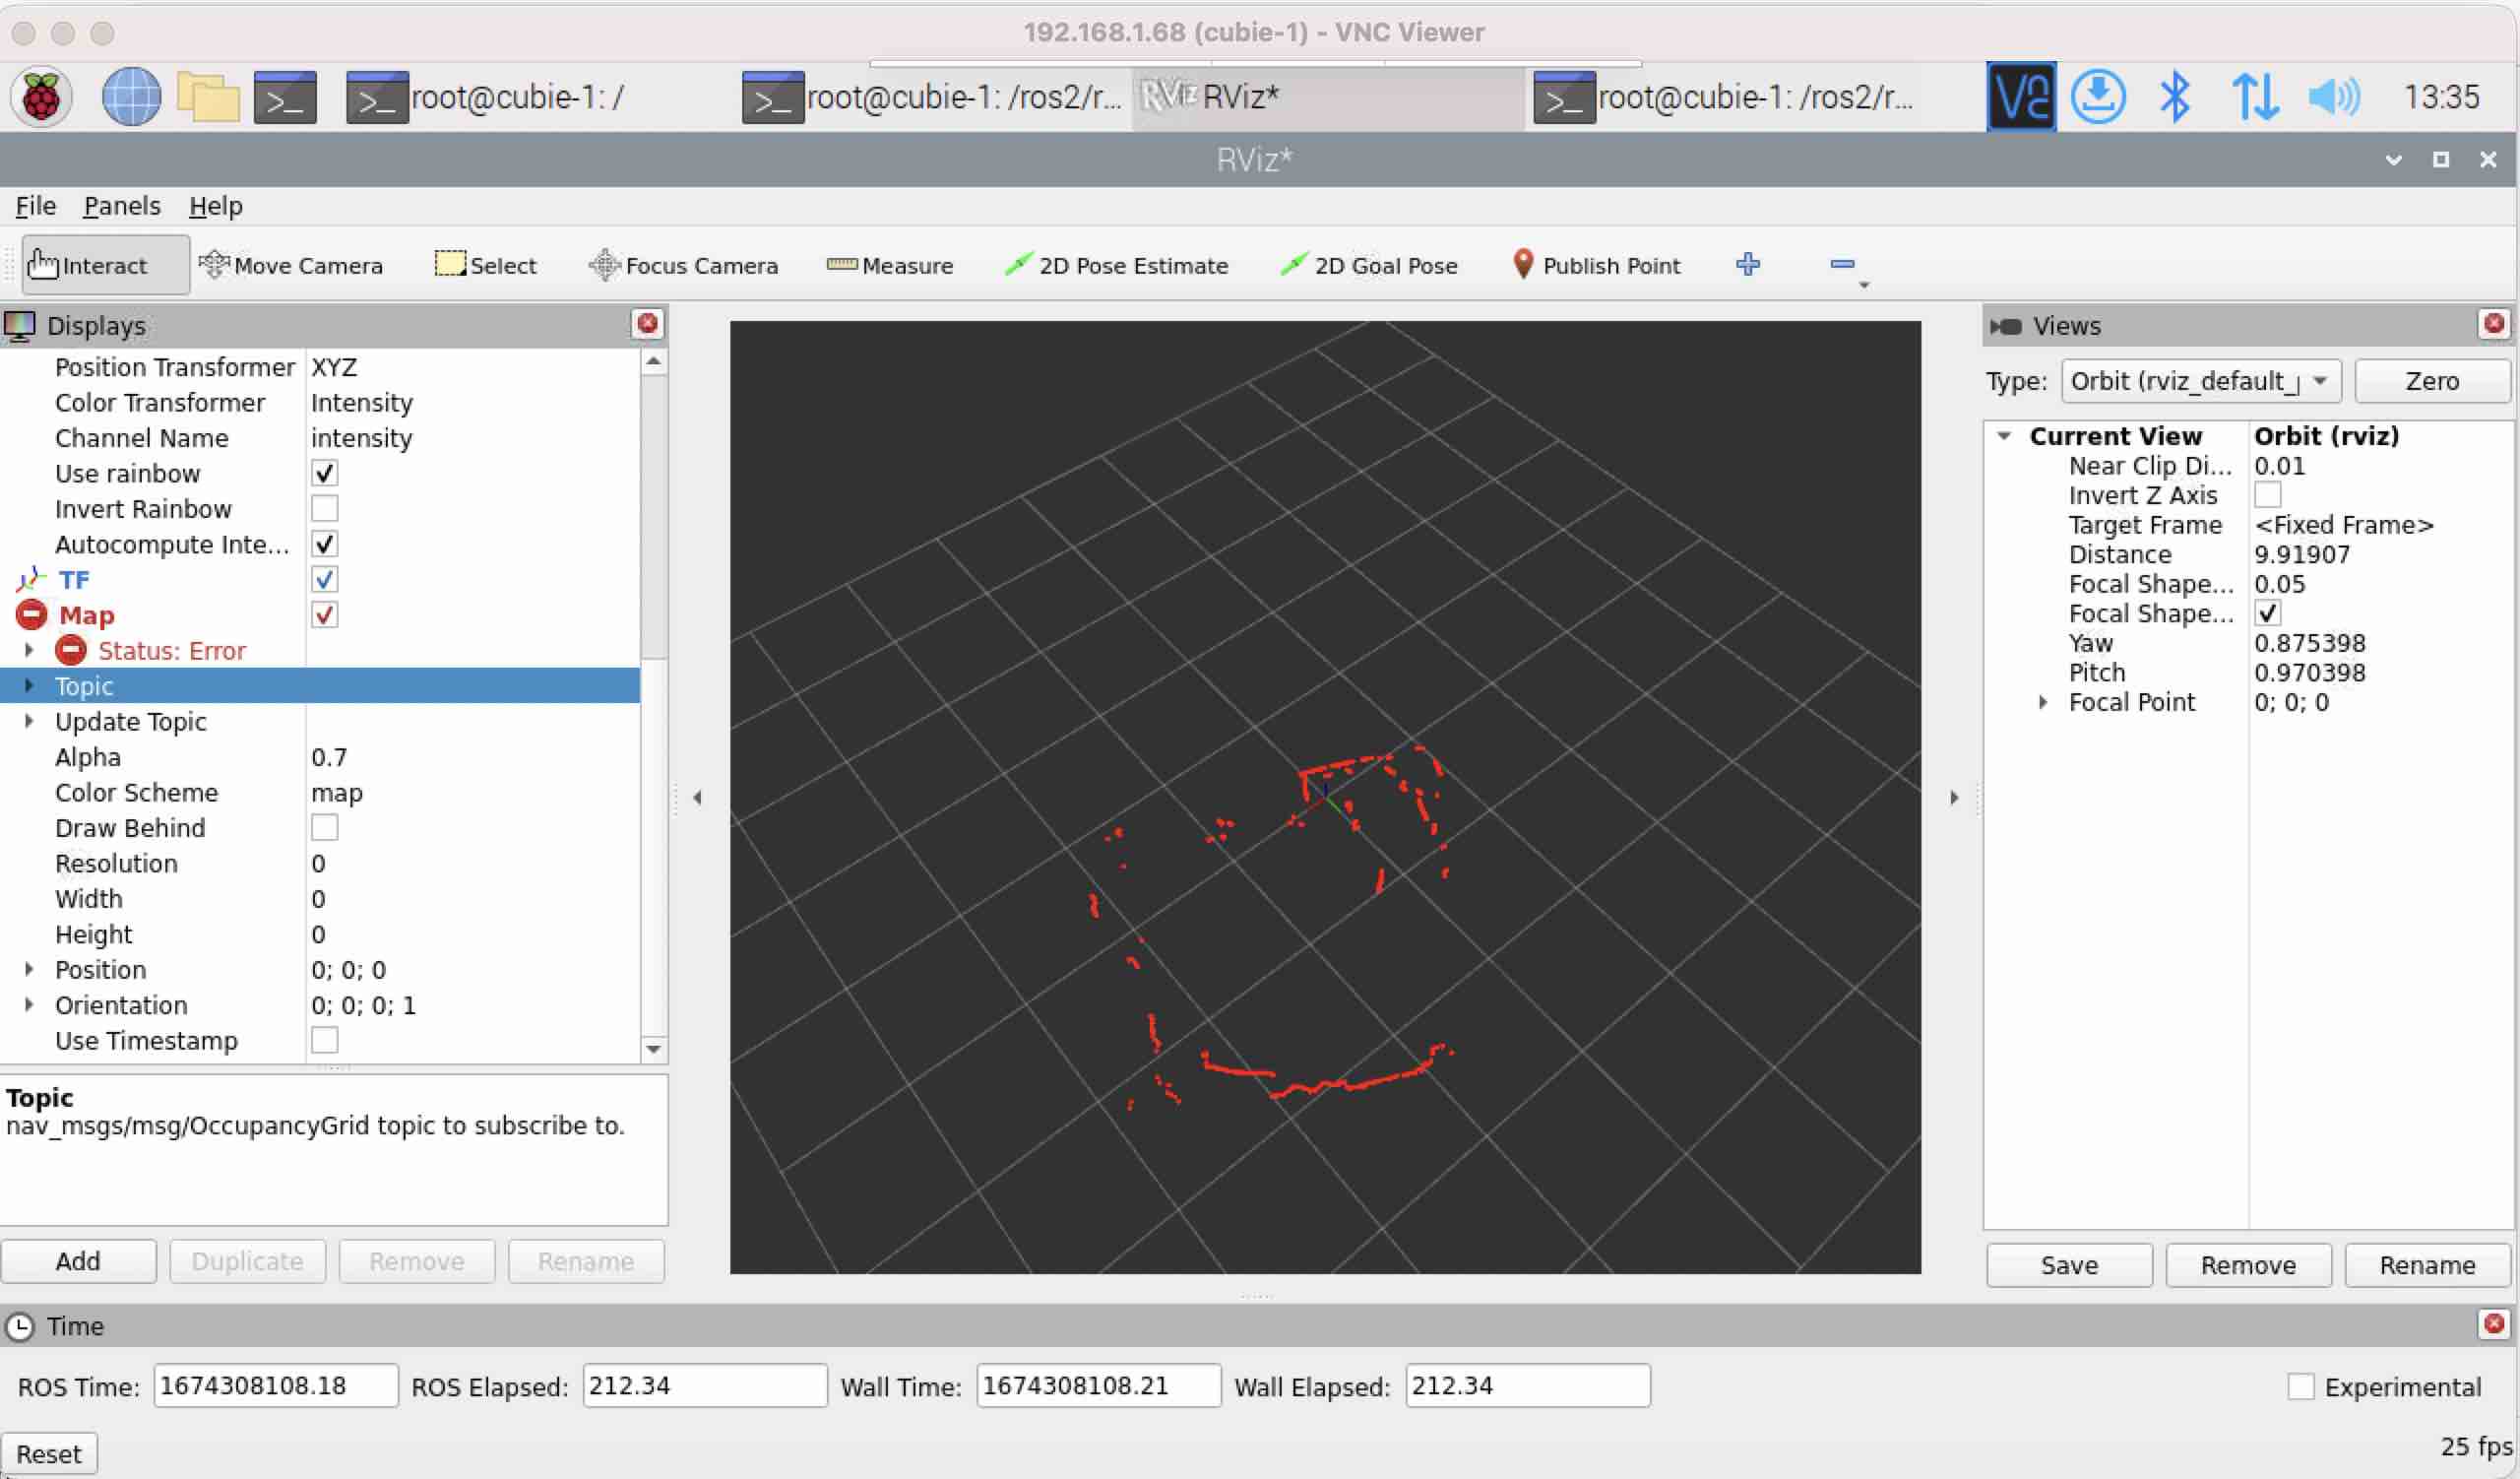
If the scan doesn’t appear, this video covers a bug I hit at this point and how I fixed it:
Check your understanding
Quick quiz 1 of 3
Why do we need a transform from laser_frame to world?
world frame.Quick quiz 2 of 3
Which topic does the RPLidar node publish its scans to?
Quick quiz 3 of 3
Why does RViz2 need X11 forwarding when it runs in Docker?
You can use the arrows ← → on your keyboard to navigate between lessons.
Comments