KevsRobots Learning Platform
Overview
Setting up the Raspberry Pi 4 environment
Setting Docker for ROS
Build the ROS2 Container
Setting up VSCode
First ROS2 Program
ROS2 Python Packages
Docker and X11
RViz2
Rviz2
Let's learn about RViz2, the ROS Visualisation tool
By , Minute
Watch the video
What is RViz2?
RViz2 is a powerful, user-friendly visualization tool that allows you to explore and analyze data in 3D. It is capable of displaying a variety of objects including robots, cameras, geometry, point clouds, and more. RViz2 is an open source tool that is available for free and is compatible with the ROS (Robot Operating System) platform.
How can we use RViz2?
We can use RViz2 to display the data from our LiDAR, and then take this further by adding in extra nodes such as the Mapping and Navigation nodes from the SLAM Toolkit.
RViz2 is included in the full desktop version of ROS2; so far we’ve only used the core version. The example files include a second Docker setup, docker-full, whose dockerfile also installs the ros-humble-desktop packages, and whose docker-compose.yml includes the DISPLAY and network_mode: host settings from the last lesson.
Build the full container
- Build and start the container - From the Raspberry Pi terminal, type:
cd ~/cubie-1/docker-full
docker compose build
docker compose up -d
If the build stops with an error about
ros-humble-desktop=0.10.0-1*not being found, edit thedockerfile, remove=0.10.0-1*from that line so the latest version is installed, and build again.
Console into the container
Let’s test out RViz2.
- launch Bash in Container - From the Raspberry Pi terminal, type:
docker compose exec ros2 bash
Launch Rviz2
- launch RViz2 - From the container terminal, type:
rviz2
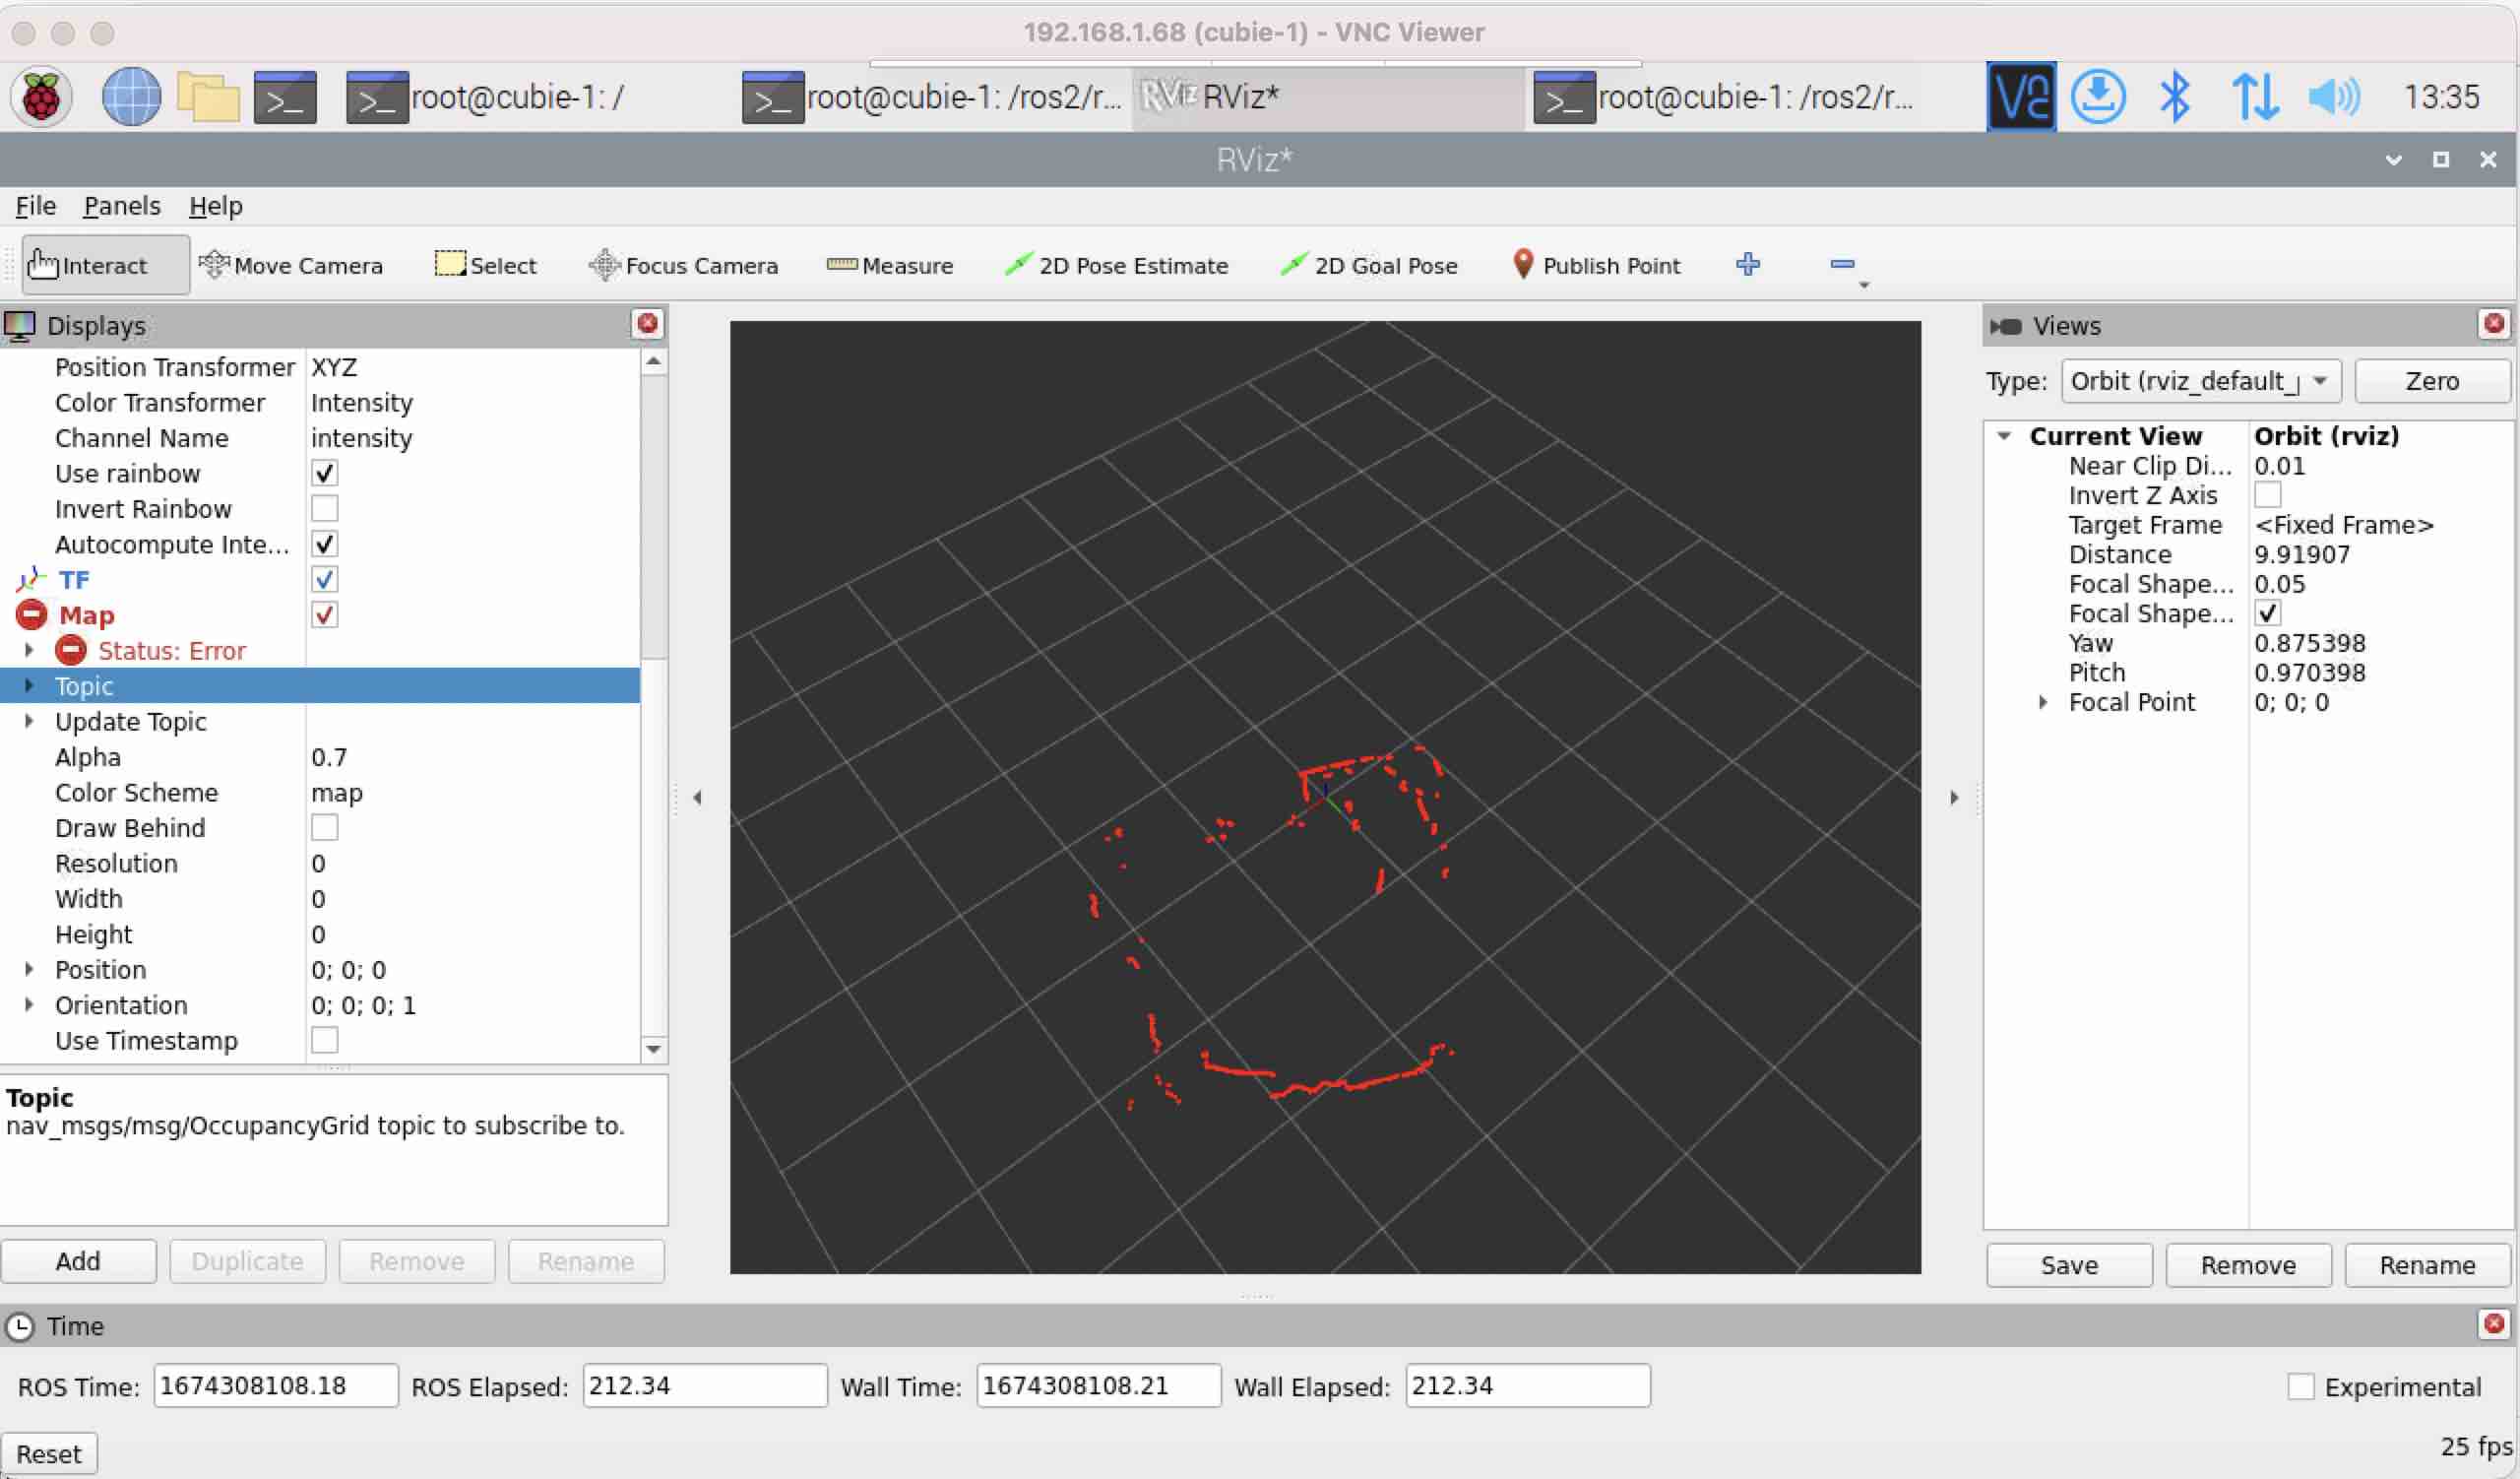
RViz should now open within the Raspberry Pi OS - this is because the container is outputting its X11 graphics commands to the Host (the Raspberry Pi OS).
You can use the arrows ← → on your keyboard to navigate between lessons.
Comments