KevsRobots Learning Platform
Build your own BurgerBot
28% Percent Complete
Overview
Assembling the parts
Installing the code
Programming in MicroPython
Upgrades
Assembly
Learn how to assemble the BurgerBot using a Raspberry Pi Pico and 3D printed parts.
By Kevin McAleer, 3 Minutes
| Step | Detail |
|---|---|
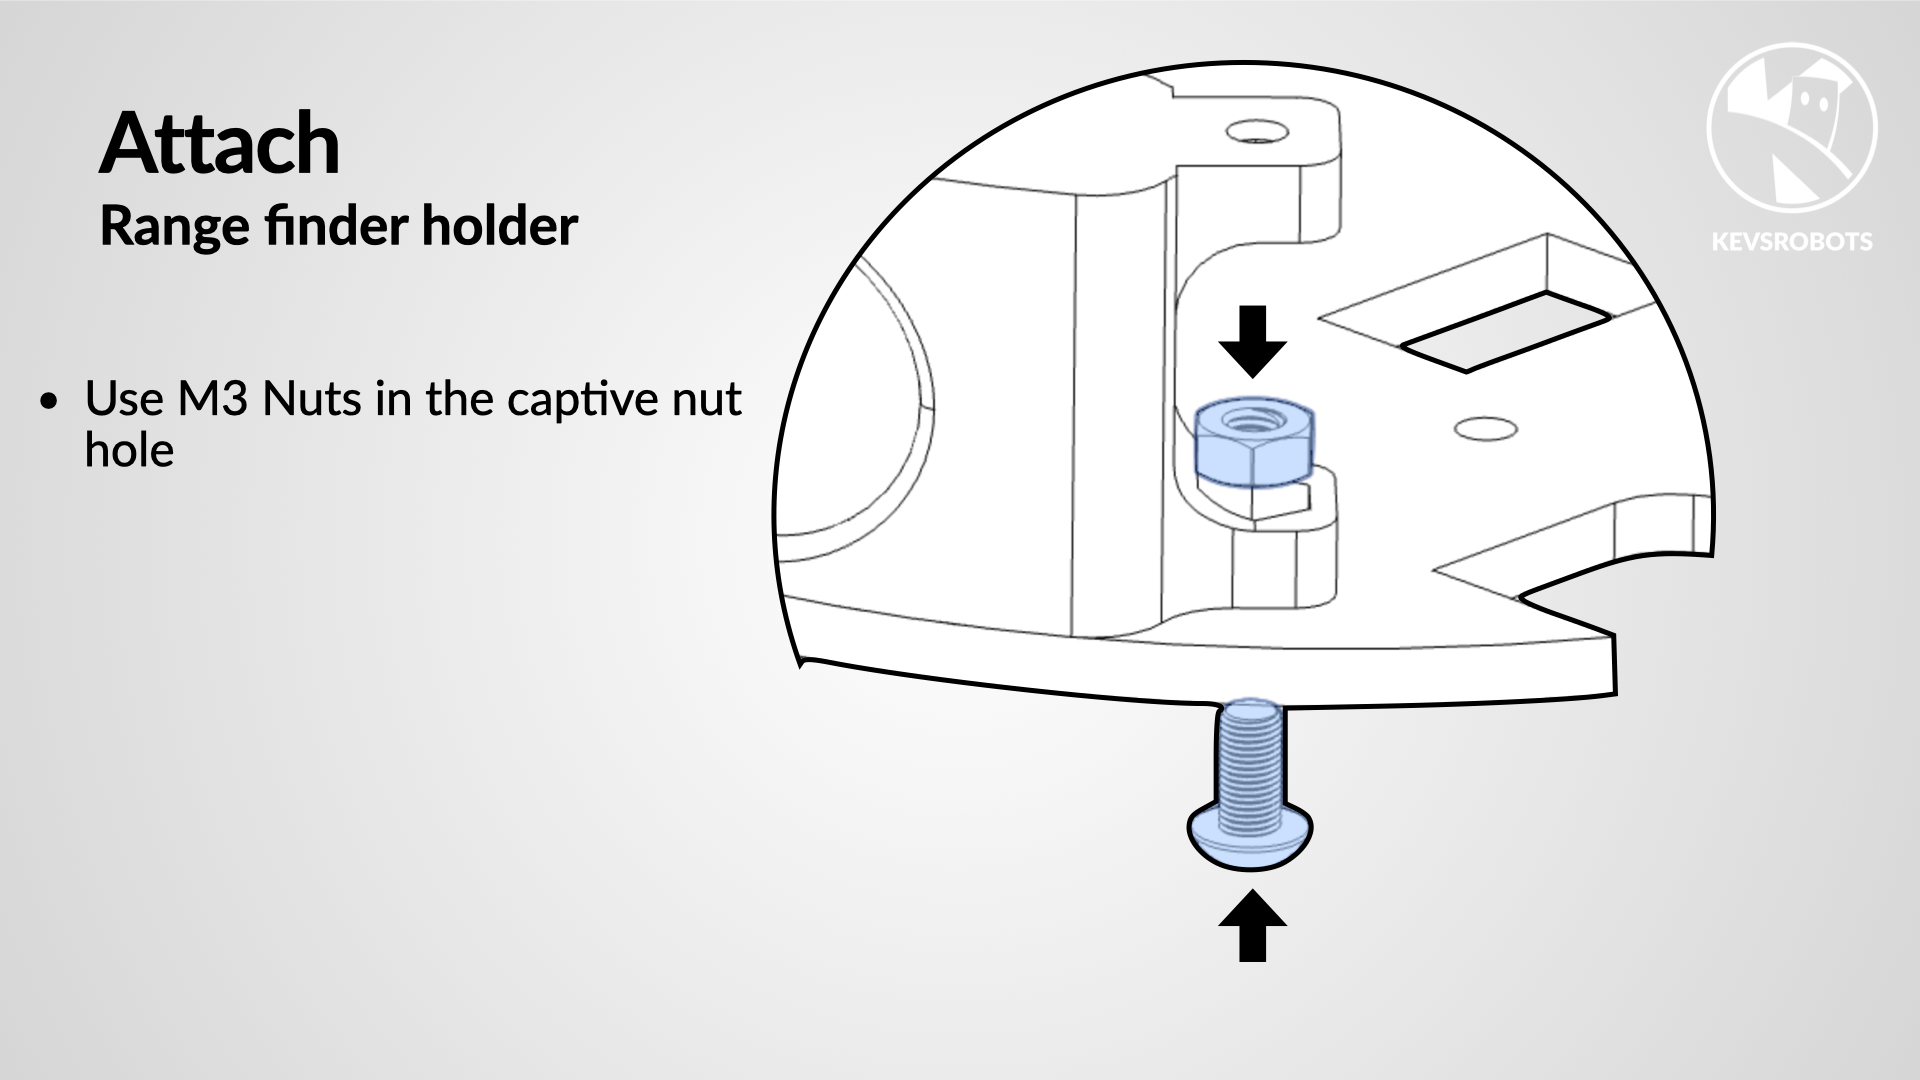 |
Use M3 Nuts in the captive nut hole |
 |
Push 2 M3 nuts into the captive nut holes in the range finder and rear support, Use 2 M3 screws to secure the range finder and rear support |
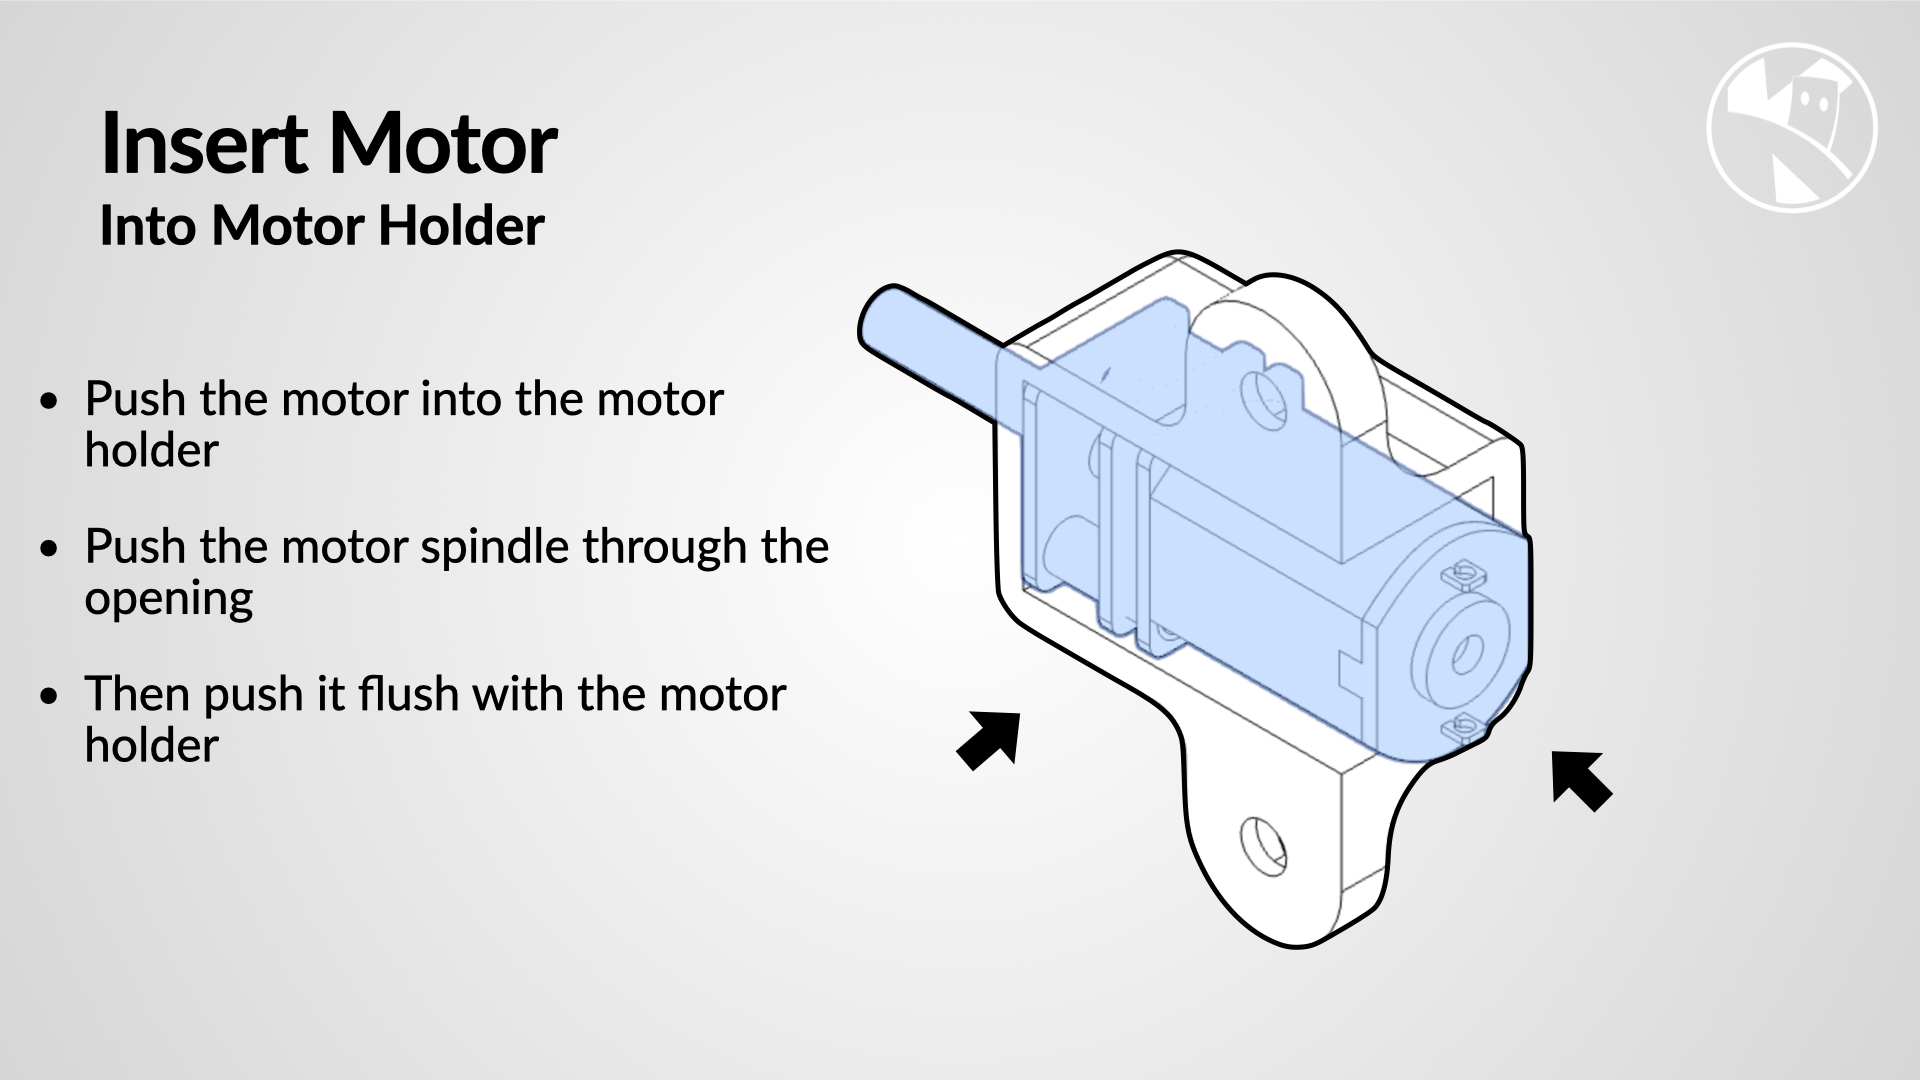 |
Push the motor into the motor holder, Push the motor spindle through the opening, Then push it flush with the motor holder |
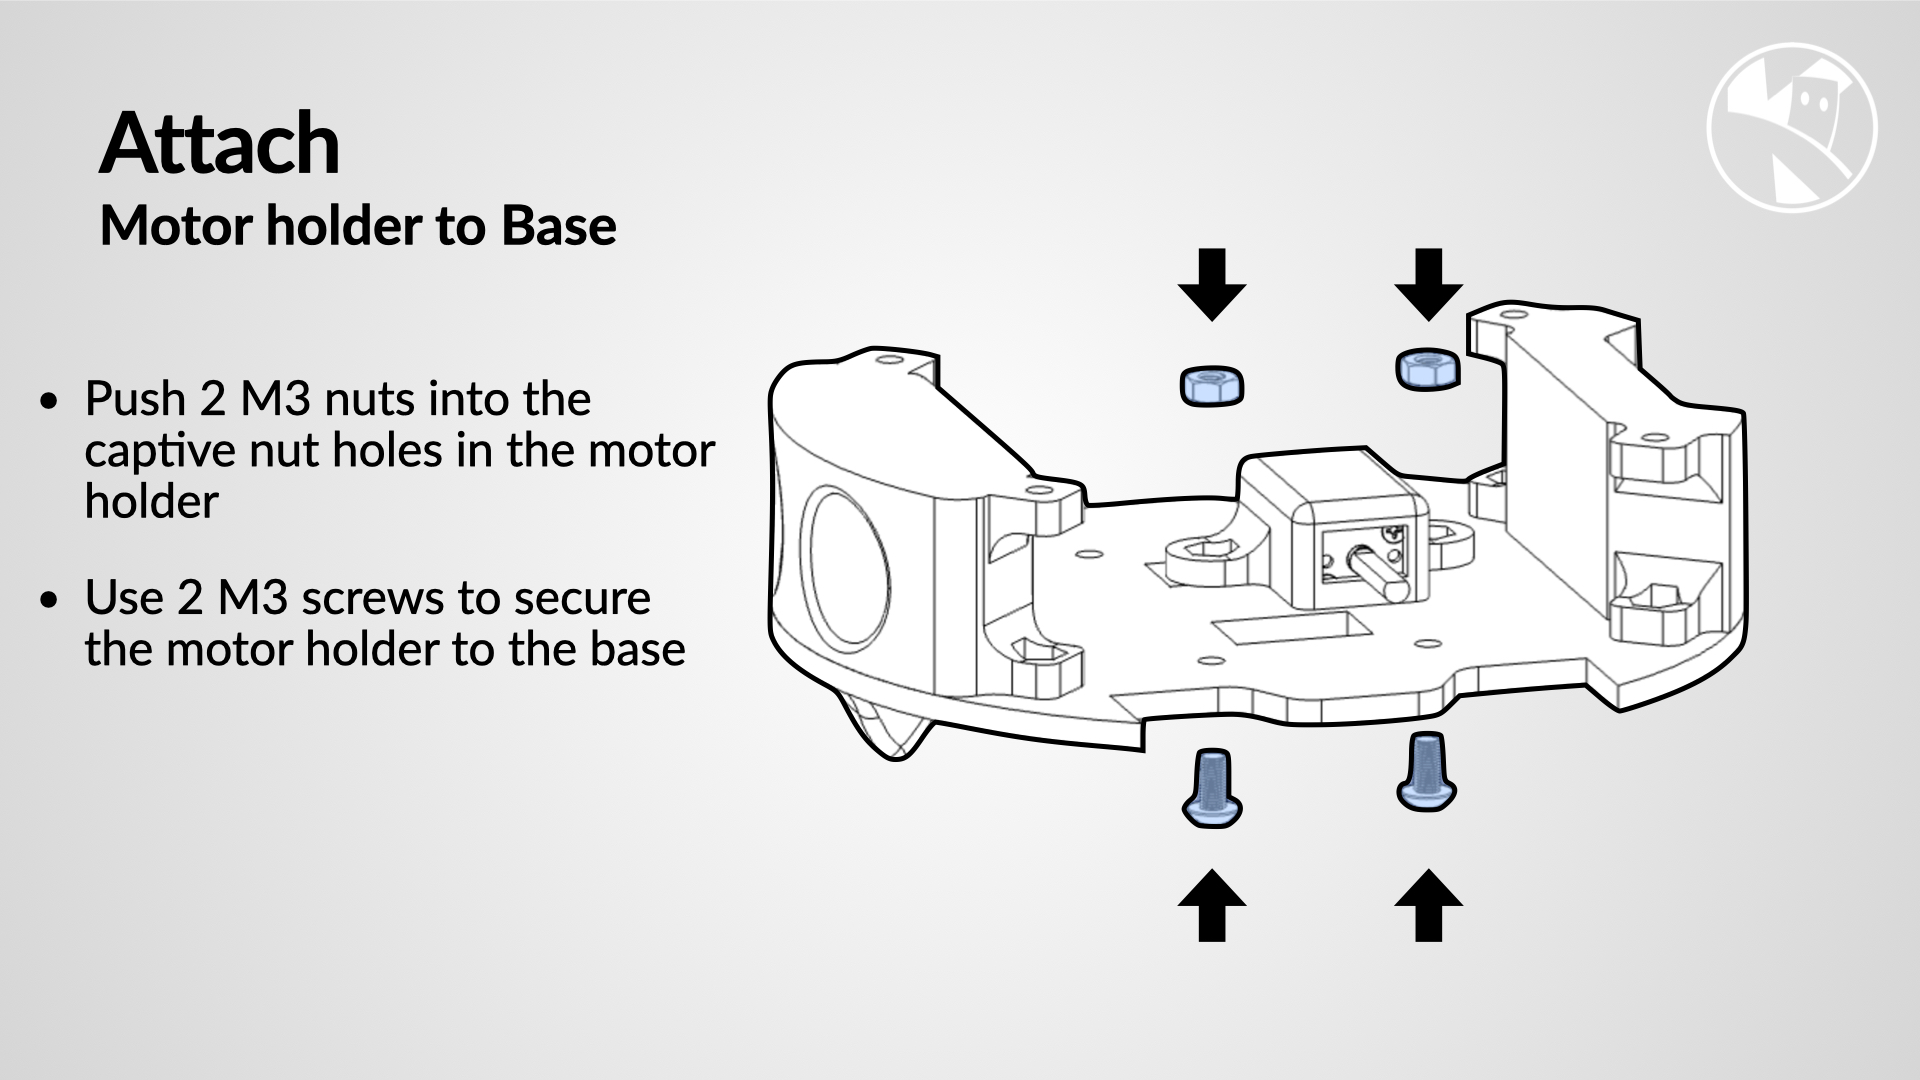 |
Push 2 M3 nuts into the captive nut holes in the motor holder, Use 2 M3 screws to secure the motor holder to the base |
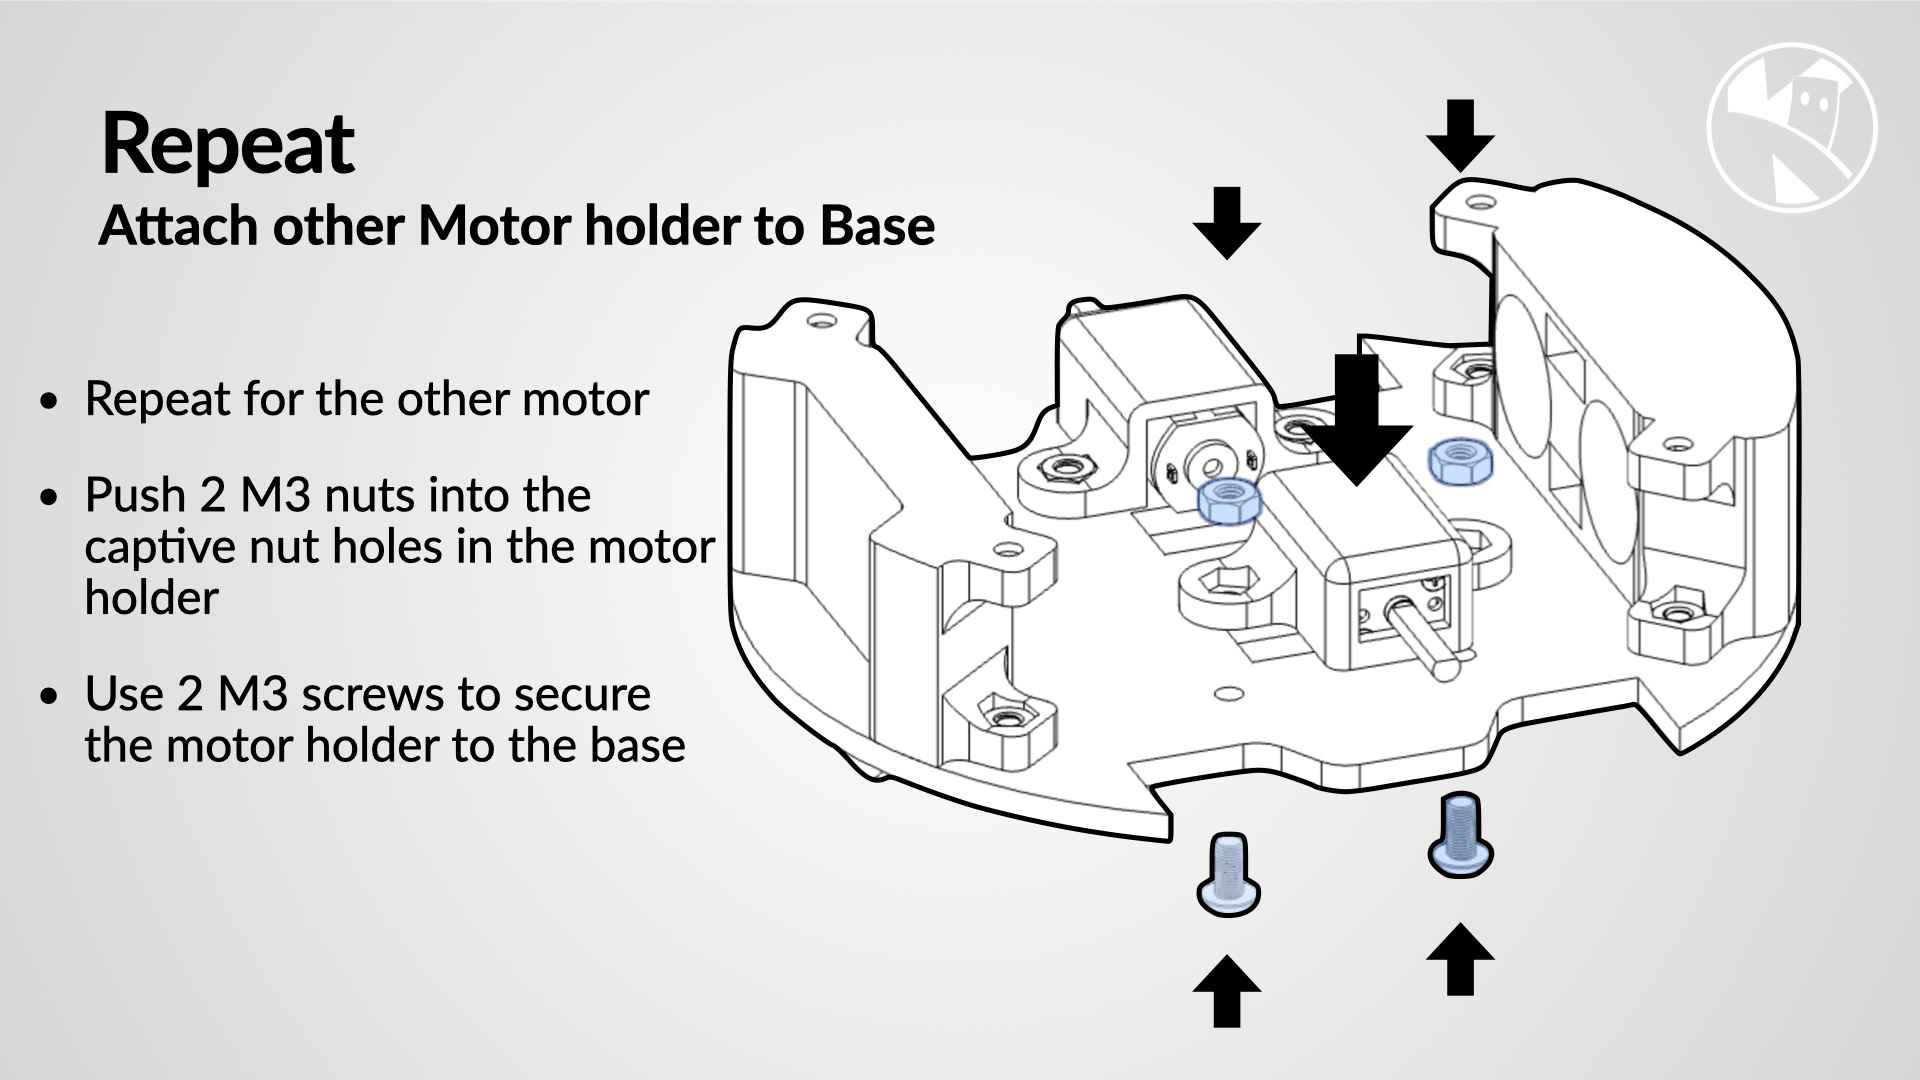 |
Repeat for the other motor, Push 2 M3 nuts into the captive nut holes in the motor holder, Use 2 M3 screws to secure the motor holder to the base |
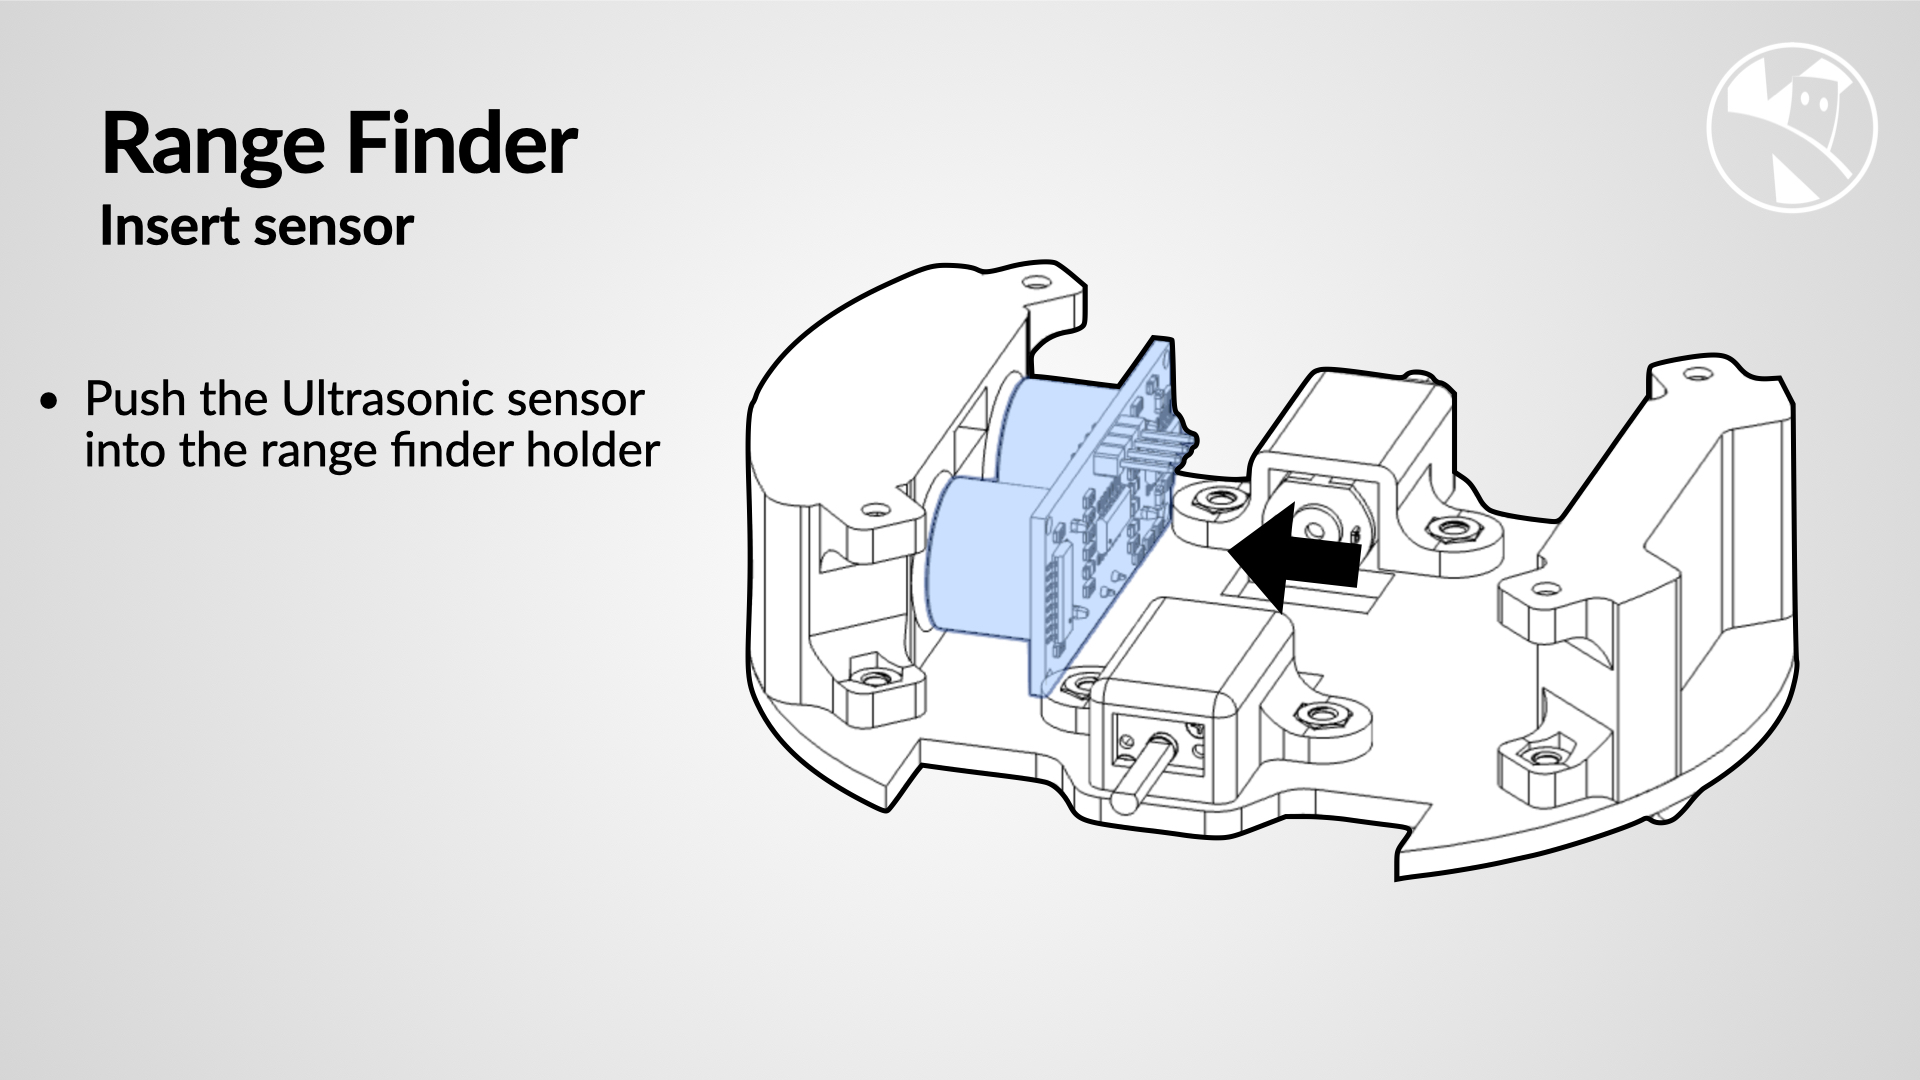 |
Push the Ultrasonic sensor into the range finder holder |
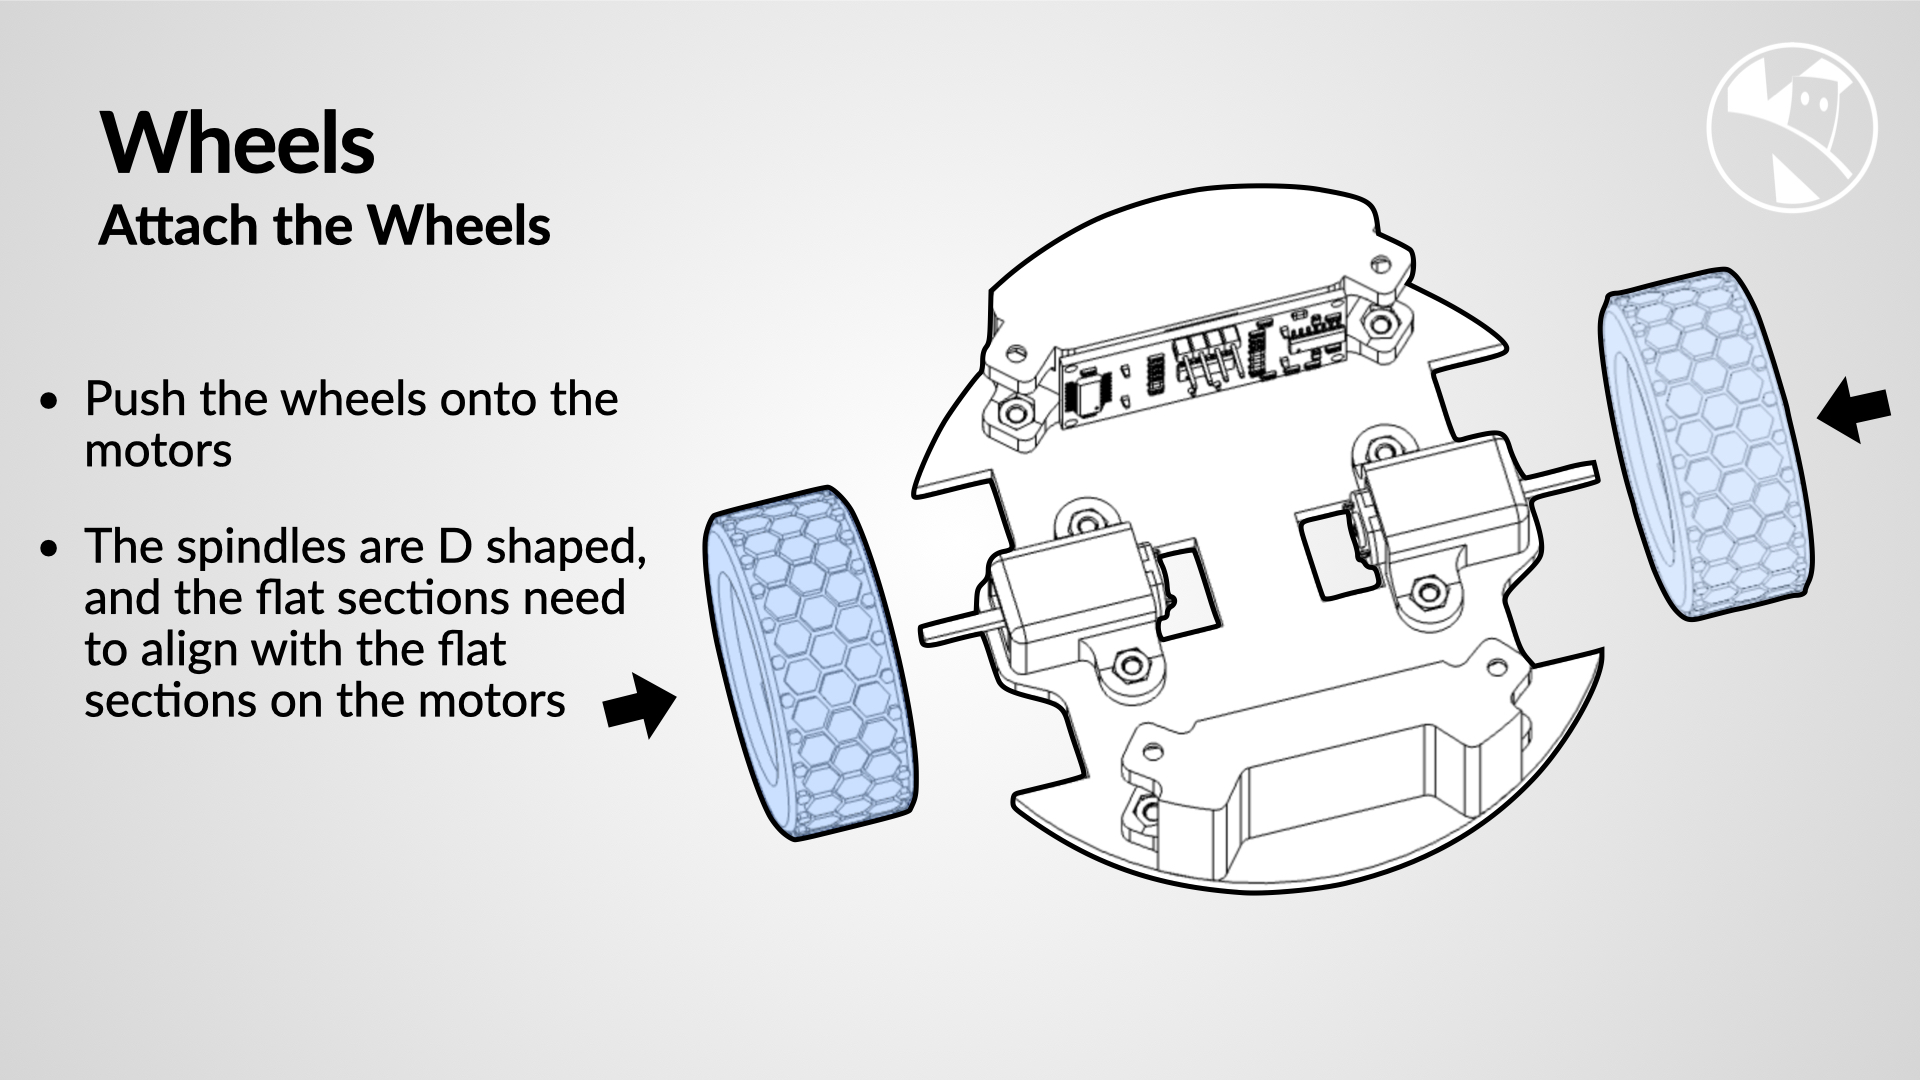 |
Push the wheels onto the motors, The spindles are D shaped, and the flat sections need to align with the flat sections on the motors |
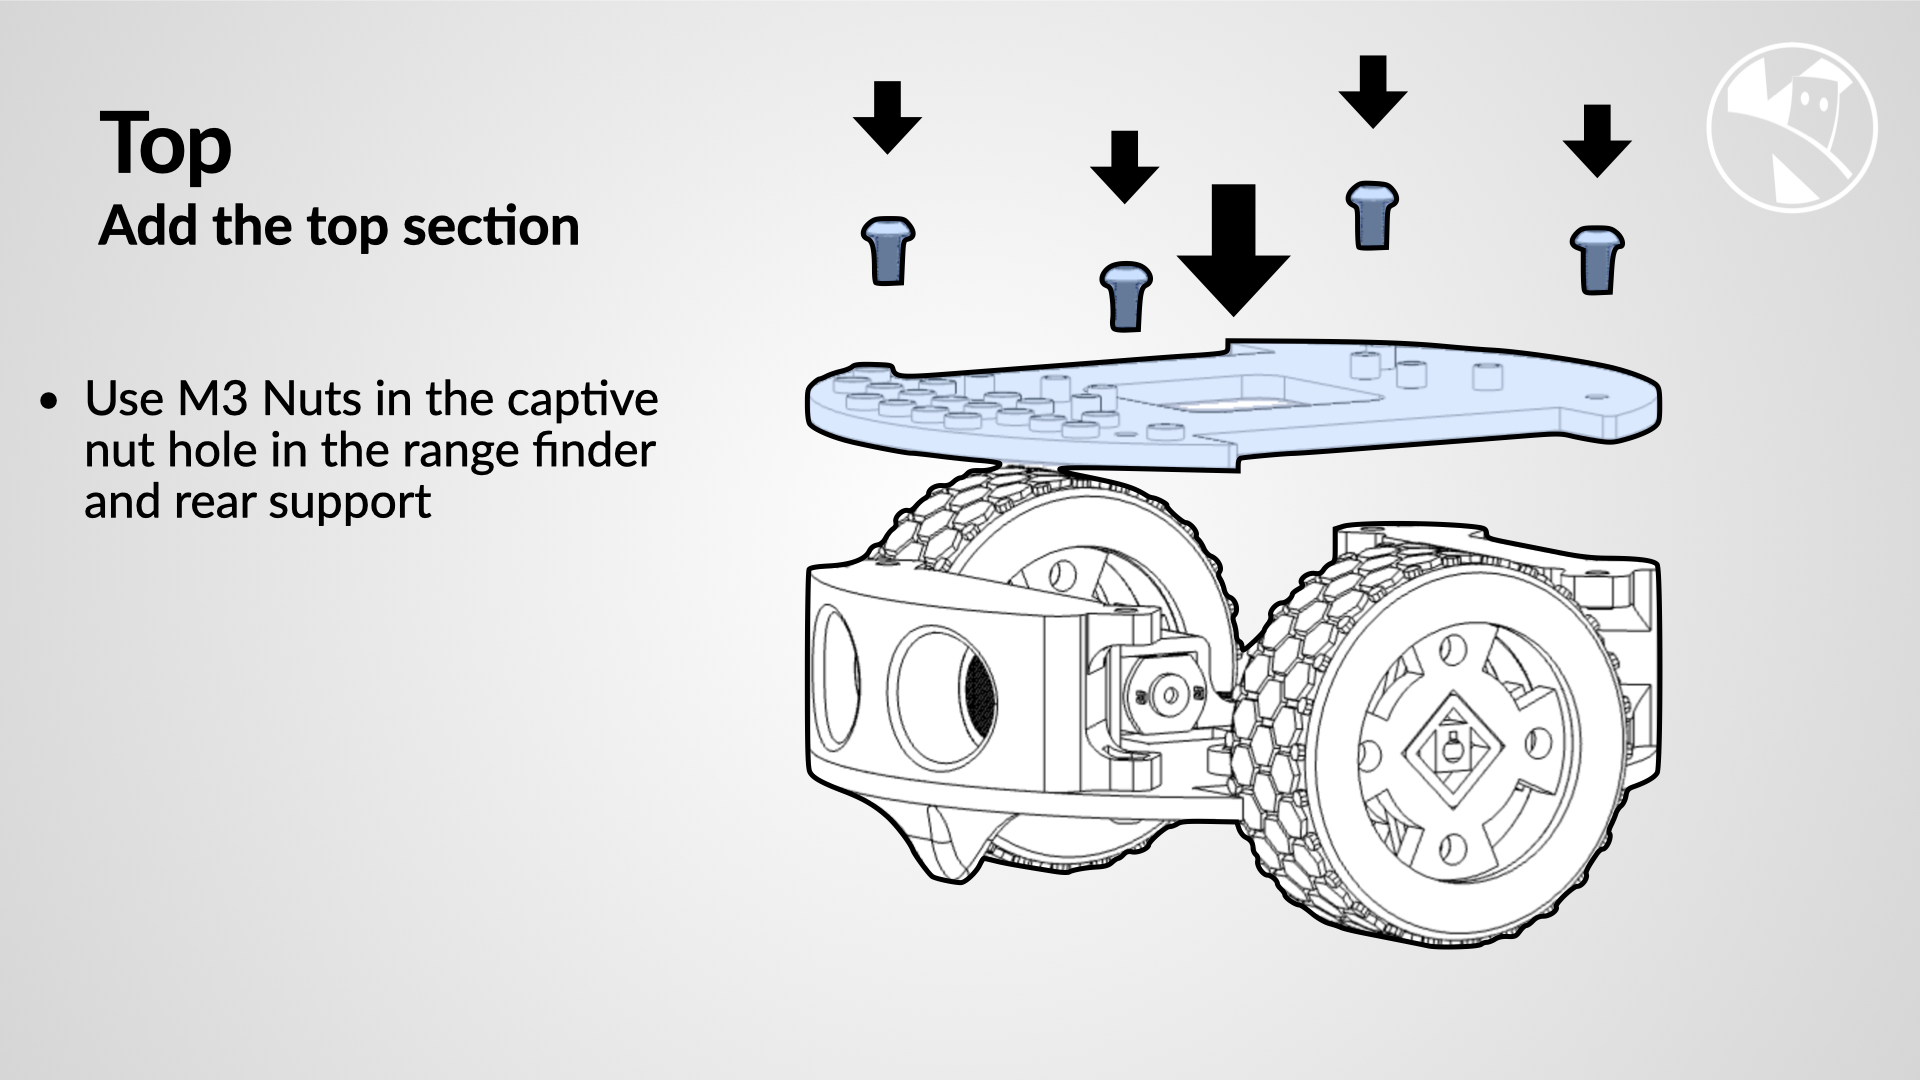 |
Use M3 Nuts in the captive nut hole in the range finder and rear support |
 |
Use M2 Screws to secure the Pico to the Top section |
Wiring and general assembly notes
- Begin by soldering the Pico lipo shim to the Pico. Apply some flux to make the soldering process easier.
- Solder the red cable to the 5 volt on the Pico. Take note of the captive nuts where the battery will be placed.
- Screw the battery in place. Be sure to screw only the left-hand side so that the Lipo shim can be placed on top.
- Connect the battery from the other side and press the button to check if the connection is working well.
- Screw the assembly onto the base, using screws and captive nuts to make a secure connection.
- Add the Pimroni motors and screw them into place. Use pliers to squish the nuts and secure them.
- Install the rangefinder and screw it into place. It has captive nuts that make it easy to screw.
- Add the thin Moon Boogie Wheels.
- Install the servo holder. It has captive knots that make it easy to put into place and secure.
- Add the pen holder and the cog that goes against it.
- Test fit the Sharpie to ensure it fits snugly.
- Add the motor cables. If you forgot to do this before, you can undo the motor holders and then re-screw them back into place.
- Crimp some female to male Dupont cables and connect the servo to the pins on the back of the Pico.
- Check your connections and run some code to test your Burger bot.
- By following these steps, you can build your own Burger bot just like the one in the video.
You can use the arrows ← → on your keyboard to navigate between lessons.
Comments