Creating Gears in Fusion 360
Learn how to create perfect gears and rack-and-pinion systems in Fusion 360 using the SpurGear add-in and a bit of clever math.
6 October 20255 minute read
By Kevin McAleer
Share this article on
Table of Contents
- Converting Rotational Motion to Linear Motion
- Getting Started with the SpurGear Add-in
- Finding the Add-in
- The Math Behind Perfect Gears
- Key Formulas
- Setting Up Your Gear
- Creating the Perfect Tooth Profile
- Making the Rack
- Copy and Position
- Project the Tooth Profile
- Calculate the Rack Length
- Pattern Those Teeth!
- Tooth Spacing Calculation
- Creating the Pattern
- Final Assembly
- Testing the Fit
- Why This Method Works
- Tips for 3D Printing Gears
- What’s Next?
Creating Gears in Fusion 360
Learn how to create perfect gears and rack-and-pinion systems in Fusion 360 using the SpurGear add-in and a bit of clever math.

Video
For every project I create, I often make a corresponding YouTube video. Sometimes, there might be more than one video for a single project. You can find these videos in this section.
Explore more through this this dedicated video.
Converting Rotational Motion to Linear Motion
Ahoy there makers! In this guide, I want to show you how to create a rack and pinion system using Fusion 360. This is absolutely ideal if you want to convert rotational energy into linear motion - perfect for robot arms, linear actuators, or any project where you need precise movement control.
Getting Started with the SpurGear Add-in
First things first, let’s fire up Fusion 360 and get our bearings. The secret weapon we’ll be using is the SpurGear add-in, which is a Python program that makes gear creation much easier than doing it manually.
Finding the Add-in
- Go to Utilities in the toolbar
- Click on Add-ins and Scripts
- Look for SpurGear (there’s a Python version and a C++ one - I’m using the Python version)
- Click Run

You’ll see a dialogue box pop up with loads of options. Don’t worry, we’ll walk through exactly what you need!
The Math Behind Perfect Gears
Here’s where things get interesting. The SpurGear dialogue wants you to specify a module, but what if you know the outer diameter you want instead? Let’s work backwards!
Key Formulas
I’ve created a simple spreadsheet to help with these calculations:
- Pitch Diameter =
Module × Number of Teeth - Module =
Outer Diameter ÷ (Number of Teeth + 2) - Rotation Angle =
360° ÷ Number of Teeth ÷ 2

For example, if I want:
- Outer diameter:
18.5mm - Number of teeth:
10
Then my module is: 18.5 ÷ (10 + 2) = 1.54
Download the spreadsheet here to play with your own values: Gear Calculation Spreadsheet
Setting Up Your Gear
Let’s create the gear step by step:
- Create a new sketch on the top plane
- Press C for circle and create two circles: 18mm and 12mm diameter
- Make them construction lines
- Run the SpurGear add-in with these settings:
- Module:
1.54 - Number of teeth:
10 - Center hole:
3mm - Gear thickness:
3mm - Root fillet:
0.9mm(needs to be under 0.9 to work with this module)
- Module:

The pitch diameter should show as 15.4mm - that’s the middle circle where the teeth mesh.

Creating the Perfect Tooth Profile
Now we need to orient that tooth correctly for copying. Here’s the trick:
- Open the Bodies section and select your spur gear body
- Press M to move it
- Select Rotate and choose the center axis
- Rotate by 18° (remember that formula? 360 ÷ 10 ÷ 2 = 18°)

This gives us two teeth perfectly aligned at the top and bottom.
Making the Rack
Now for the clever bit - creating the rack that our gear will mesh with!
Copy and Position
- Press M again to move/copy
- Select Translate and move in the Y-axis by -15.4mm (the pitch diameter)
- Make sure Create Copy is checked
- Click OK

You’ll see the teeth overlapping - that’s exactly what we want!
Project the Tooth Profile
- Hide the original gear body
- Create a new sketch on the top surface
- Press P to project
- Carefully select and project all the lines that make up one tooth profile
- Draw a line across the bottom to close the profile
- Press E to extrude the tooth out by 3mm

Calculate the Rack Length
For the full rack:
- Go back into the sketch
- Create a rectangle: 3mm high × 190mm long (or whatever length you need)
- Extrude this base by 3mm as well
Pattern Those Teeth!
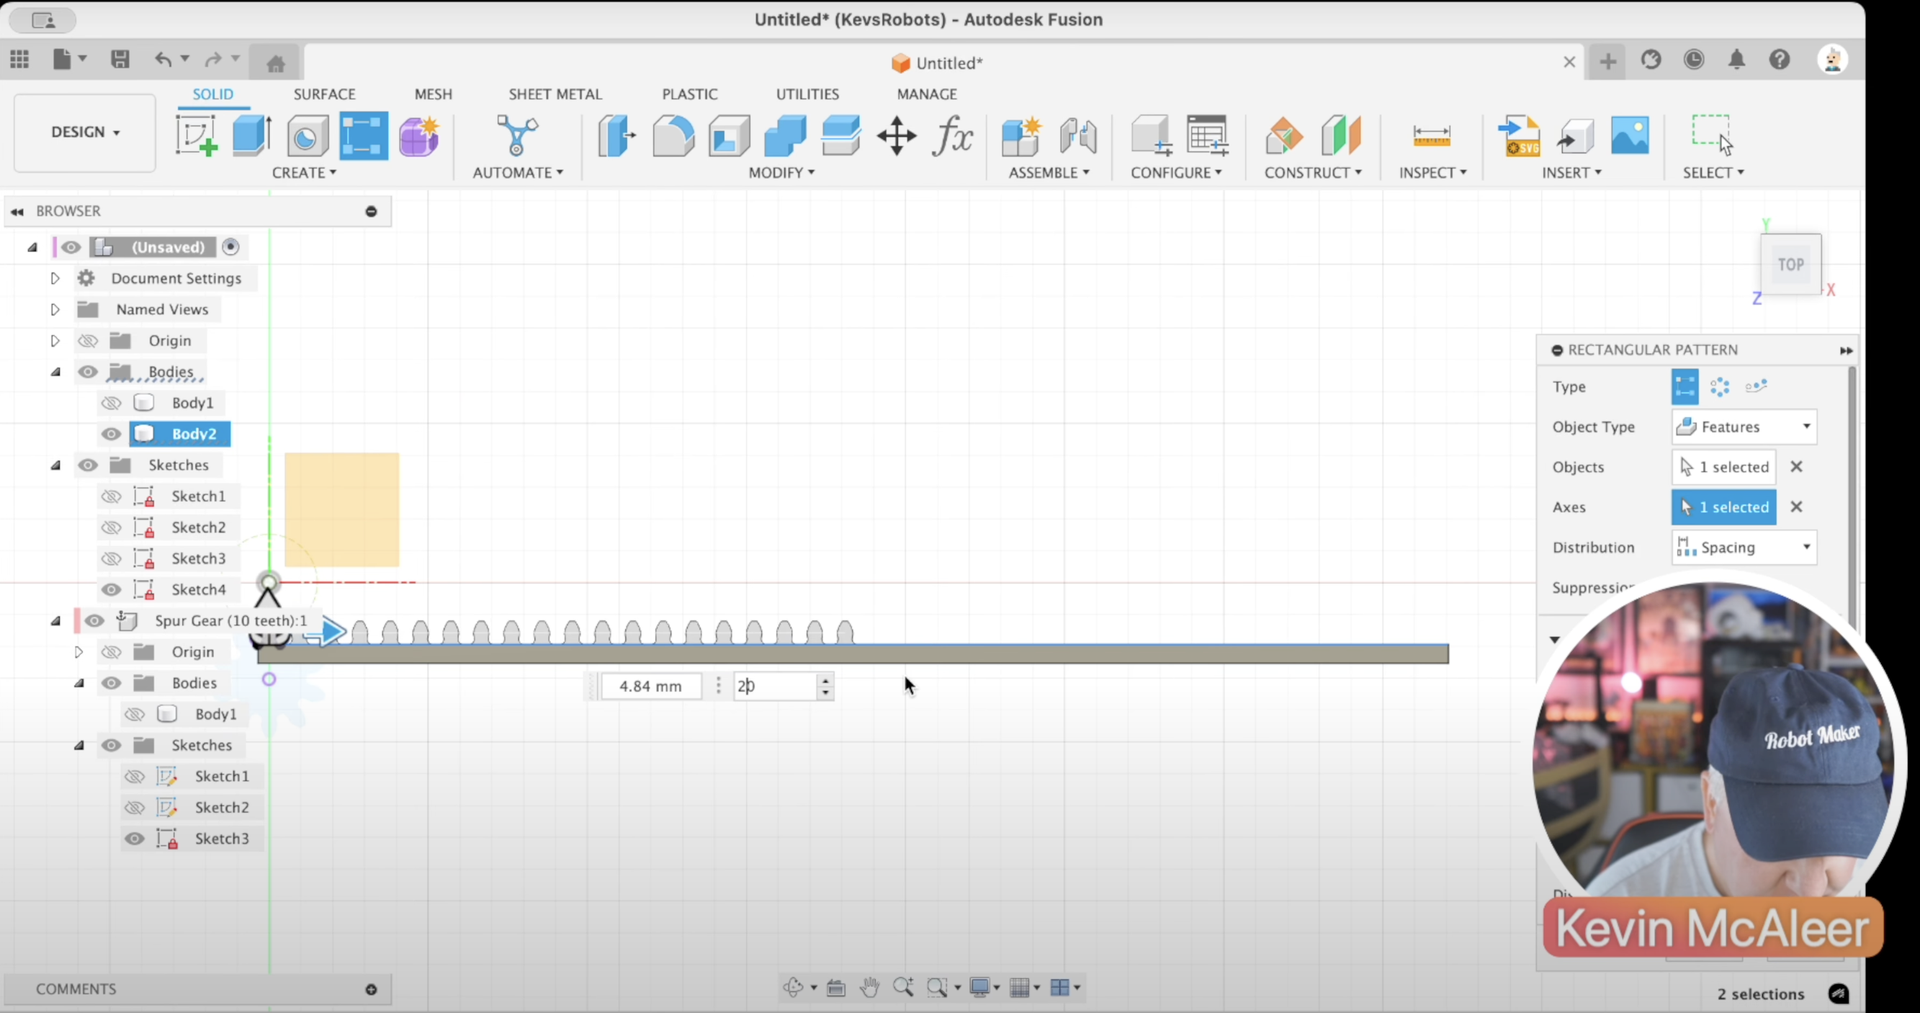
Now we need to replicate that single tooth along the entire rack.
Tooth Spacing Calculation
The spacing between teeth is critical:
Spacing = (Pitch Diameter × π) ÷ Number of Teeth
For our example: (15.4 × π) ÷ 10 = 4.84mm
Creating the Pattern
- Go to Create → Pattern → Rectangular Pattern
- Select the tooth extrusion as the feature
- Set the direction along the rack
- Set spacing to 4.84mm
- For a 190mm rack, you’ll need about 39 teeth
Final Assembly
- Select all the bodies
- Use Combine with the Join operation
- You now have a single, complete rack!
Testing the Fit
Let’s verify everything meshes properly:
- Show the original gear body again
- Press M to rotate it back by -18° to undo our earlier rotation
- Zoom in and check the mesh

The teeth should fit together perfectly with no gaps or interference. If they do, you’re ready to 3D print!
Why This Method Works
The beauty of this approach is that we’re working from the outer diameter - the actual physical size we need - rather than getting confused by pitch diameters and modules. The math is straightforward, and once you’ve got the formulas in a spreadsheet, you can quickly design gears of any size.
The involute curve of the tooth profile (that lovely curve you see) is what makes gears mesh smoothly without binding. The SpurGear add-in handles all that complex geometry for us.
Tips for 3D Printing Gears
- Add a bit of tolerance (0.1-0.2mm) if your printer isn’t super precise
- Print gears flat on the bed for best accuracy
- Consider the layer orientation for strength
- Test with a small sample before printing the full rack
What’s Next?
Now you’ve got the skills to create custom gears and racks for all sorts of projects! Try experimenting with different tooth counts, sizes, and ratios. You could even create complete gearbox assemblies.
Hope this helps you with your next robot build! Let me know what you create with these techniques.
Bye for now, and happy making!
This page is awesome - Show some love!
Comments