Simple Robot Arm
Build your own Robot Arm
25 September 20228 minute read
By Kevin McAleer
Share this article on
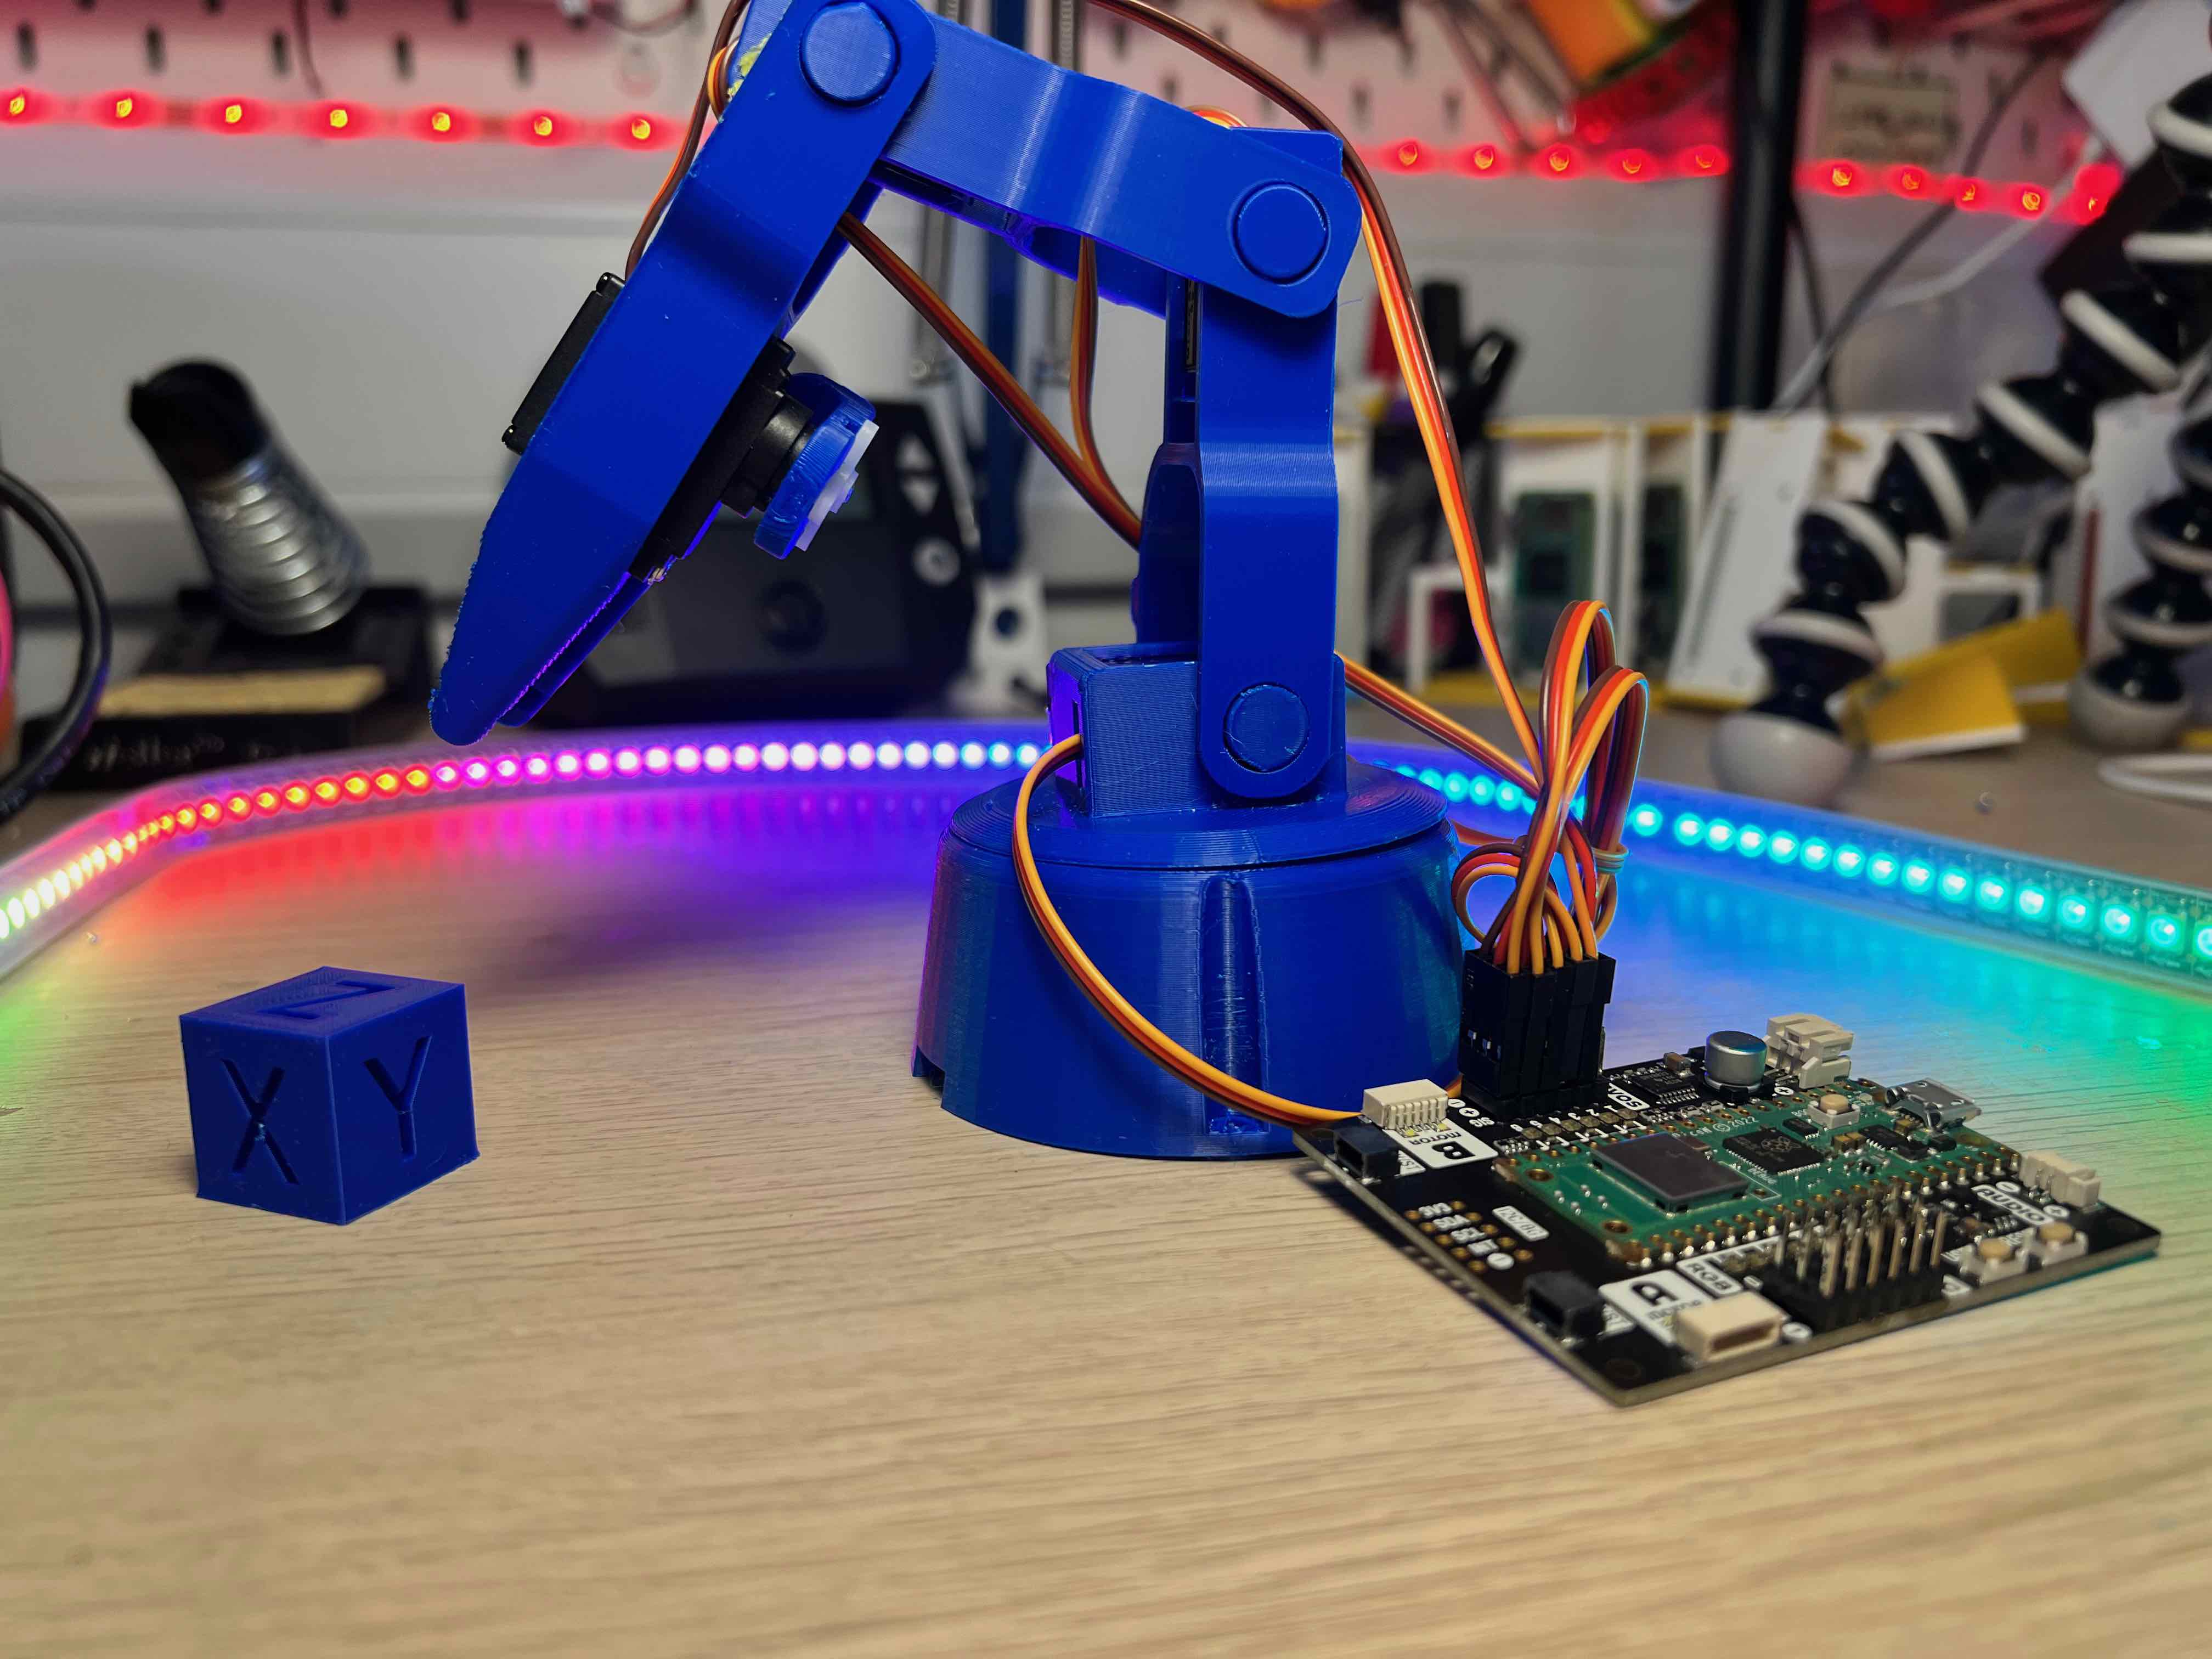
Build your own Robot Arm
25 September 2022
By Kevin McAleer
Share this article on
Watch the associated video here:
Grab the 3d printable STL files for the Grippy-Bot from Cult 3d - https://cults3d.com/en/3d-model/gadget/grippy-bot. This model is a free to download, and is pretty quick to 3d print. I used the Cura slicer with ‘Standard’ print settings and these worked out fine. I managed to print all the items on the build plate at the same time.
| Part | Description | Qty | Cost |
|---|---|---|---|
| SG90 Servo | These are the motors that move the parts of the arm | 5 | £4.00 |
| Inventor 2040 W | This is the brains of the Robot arm and will provide Wi-Fi access. Available from Pimoroni | 1 | £34.50 |
You’ll probably find packs of Servos online cheaper than buying them individually.
This project enables you to control the robot arm over Wi-Fi, using the amazing Phew! library from Pimoroni. Phew provides simple functions for creating an Access Point, serving Webpages from the Pico W and a templating engine for embedding variables in those web pages.
Download the code from here: https://www.github.com/kevinmcaleer/inventor_arm
You’ll need to install Phew! on the Pico W, and copy over the index.html file too. You can upload files using Thonny (Right click on the files and folders to upload from the thonny files menu). If you want to know more about how to install Phew! Watch this part of this video
There are two MicroPython programs in the repository:
test01.py - A simple test program to check the motors are working - they will all move from their minimum to maximum valuestest02.py - This is the main program, it will display a web-based user interface on the IP address logged to the console. Just type that address into the web browser of any device, phone, table or computer on the same network to access the Robot Arm webpage.There are two parts to the robot arm code - the MicroPython that runs on the Inventor 2040 W, and the Javascript that runs on the browser, from the index.html file.
The Wi-Fi SSID and Password are defined in a config.py file on the Pico W - if this doesn’t exist you’ll need to create it with the following content:
wifi_ssid = '<enter your Wi-Fi name here>'
wifi_password = '<enter your Wi-Fi password here>'
The first block of code brings in all the software libraries needed for this project, including the phew! library, and the Inventor 2040 W library.
from phew import *
from phew import connect_to_wifi, server, logging
from phew import render_template
from config import wifi_ssid, wifi_password
from inventor import Inventor2040W, SERVO_1, SERVO_2, SERVO_3, SERVO_4, SERVO_5, SERVO_6
from time import sleep
import math
The next block of code connects to the Wi-Fi network, creates a board variable and sets each of the servos to its middle position.
# Connect to Wi-Fi
ip = connect_to_wifi(wifi_ssid, wifi_password)

# Create a new board
board = Inventor2040W()

# Set all servos to mid position
for servo in board.servos:
    servo.to_mid()
    print(f'servo: {servo}, value {servo.value()}')
    sleep(0.1)
We create a position function to take values passed to it from the webserver and sets the servos accordingly.
def position(arm=None, wrist=None, elbow=None, finger=None, base=None):
    """ Set the servo positions """
    if finger is not None:
        board.servos[SERVO_2].value(finger)
    if wrist is not None:
        board.servos[SERVO_3].value(wrist)
    if arm is not None:
        board.servos[SERVO_4].value(arm)
    if elbow is not None:
        board.servos[SERVO_5].value(elbow)
    if base is not None:
        board.servos[SERVO_6].value(base)
    sleep(0.01)
The next block of code listens to any web requests to the / url and either send the rendered index.html file back to the users browser, or processes the servo slider positions, one for each of the servos.
@server.route('/', methods=['GET','POST'])
def index(request):

    if request.method == 'GET':
        return render_template('index.html')
    elif request.method == 'POST':

        elbow = request.form.get("elbow", None)
        arm = request.form.get("arm", None)
        base = request.form.get("base", None)
        finger = request.form.get("finger", None)
        wrist = request.form.get("wrist", None)
        if elbow is not None:
            position(elbow=int(elbow))
        if arm is not None:
            position(arm=int(arm))
        if base is not None:
            position(base=int(base))
        if wrist is not None:
            position(wrist=int(wrist))
        if finger is not None:
            position(finger=int(finger))

        # Try without the line below to speed up the response
        return render_template('index.html')
The last block of code shows the IP address of the Inventor 2040 W after it connected to Wi-Fi earlier, and then starts the Webserver.
# Show the IP Address
logging.info(f'IP: {ip}')
logging.is_disabled = True

# Start the server
server.run()
The other code we need runs on the users browser and is therefore written in Javascript:
function post_values()
{
  $.post(
  "",
  { elbow: elbow.value, base: base.value, arm: arm.value, wrist: wrist.value, finger: finger.value },
  function(data) {

  }
);
};
This code takes the values from each of the sliders and posts them to the webserver. It uses JQuery to simplify the code required to post values back to the webserver. Javascript can look a bit esoteric to the uninitiated - I’m not a massive fan of the language as its now obvious whats going on from the code itself, and it requires a firm understanding of the grammar and syntax to have the vaguest of clues as to what is going on.
Wiring up the robot arm is pretty simple - just plug each of the servo connectors into the Inventor 2040 W using the connections as shown below:
| Servo | Inventor 2040 |
|---|---|
| Finger | Servo 2 |
| Wrist | Servo 3 |
| Arm | Servo 4 |
| Elbow | Servo 5 |
| Base | Servo 6 |

The Web UI has 5 sliders - one for each of the servos. The middle position corresponds to the Servos middle position.

If you move the slider and then release the mouse button, the servo will then move to the position selected. The Pico Phew! library will find it difficult to move the servo in realtime sync with the slider - ask me how I know!
This is a great starter project to experiment with robotics. There are lots of area to improve upon this project including:
Kevin McAleer
I build robots, bring them to life with code, and have a whole load of fun along the way
Social Links:
If you found this high quality content useful please consider supporting my work, so I can continue to create more content for you.
I give away all my content for free: Weekly video content on YouTube, 3d Printable designs, Programs and Code, Reviews and Project write-ups, but 98% of visitors don't give back, they simply read/watch, download and go. If everyone who reads or watches my content, who likes it, helps fund it just a little, my future would be more secure for years to come. A price of a cup of coffee is all I ask.
There are a couple of ways you can support my work financially:
If you can't afford to provide any financial support, you can also help me grow my influence by doing the following:
Thank you again for your support and helping me grow my hobby into a business I can sustain.
- Kevin McAleer


Comments